google-deepmind/dm-control
Control Suite bodies and a Kinova Jaco arm from dm_control.
bench eval run \
  -d google-deepmind/dm-control@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- DeepMind Control Suite bodies
- Simulator
- dm_control 1.0.47 (MuJoCo 3.14.0)
- Requirements
- CPU only · 2 GB memory ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from dm_control (DeepMind Control Suite and dm_control.manipulation) by Google DeepMind, Apache-2.0
@misc{robouse_google_deepmind_dm_control_0_1,
  title        = {Robo Use google-deepmind/dm-control 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/google-deepmind/dm-control/}},
  note         = {BenchFlow dataset, tag google-deepmind/dm-control-v0.1, commit bcd0d002b9df; adapted from dm_control (DeepMind Control Suite and dm_control.manipulation) (Google DeepMind)}
}17 tasks
Size
Step budget
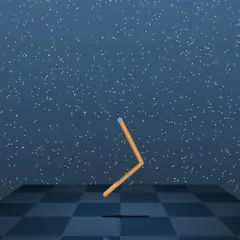
dmcontrol-acrobot-swingupAn acrobot from the DeepMind Control Suite (MuJoCo): a two-link pendulum in the x-z plane (z up). The upper arm hangs from an unactuated shoulder…An acrobot from the DeepMind Control Suite (MuJoCo): a two-link pendulum in the x-z plane (z up). The upper arm hangs from an unactuated shoulder hinge at (x, z) = (0, 2); the lower arm is attached at the elbow, the only motor. Each link is 1 m long and weighs 1 kg; both joints have light damping. Angles are in radians: shoulder_angle 0 = upper arm pointing straight up (+-pi = hanging down), elbow_angle is the lower arm's angle relative to the upper arm (0 = straight); positive angles turn towards +x. The target is the point straight above the shoulder at full height, (0, 4). Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies3,000 stepsends when first reached
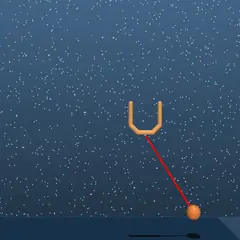
dmcontrol-ball-in-cup-catchBall in cup from the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, gravity on). A cup (0.065 kg; an open V-bottomed cup, about 8 cm…Ball in cup from the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, gravity on). A cup (0.065 kg; an open V-bottomed cup, about 8 cm wide inside the rim and 10 cm deep, opening upwards) is held by springs: it slides in x and z about its home position (0, 0.6) with a stiffness of 20 N/m and damping of 3 N s/m per axis. A ball (0.065 kg, 2.5 cm radius) hangs from the bottom of the cup on a 0.3 m string, which goes slack when the ball comes closer. The cup's position cup_pos is the centre of its rim (the bottom is 0.1 m lower). The ball starts at rest somewhere below the cup. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
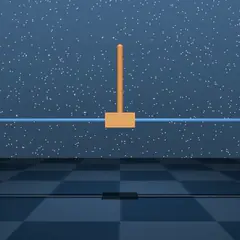
dmcontrol-cartpole-balanceA cart-pole from the DeepMind Control Suite (MuJoCo). A cart (1 kg) slides on a rail along x (x = 0 in the middle, stops at x = +-1.8 m); a pole…A cart-pole from the DeepMind Control Suite (MuJoCo). A cart (1 kg) slides on a rail along x (x = 0 in the middle, stops at x = +-1.8 m); a pole (1 m long, 0.1 kg) swings freely on an unactuated hinge on the cart, in the x-z plane (z up). pole_angle is in radians: 0 = pointing straight up, +-pi = hanging straight down; a positive angle tilts the top of the pole towards +x. The fixed camera looks along +y, so +x is to the right in the image. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
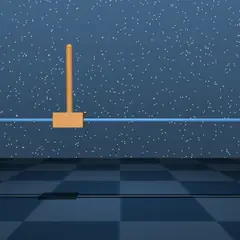
dmcontrol-cartpole-swingupA cart-pole from the DeepMind Control Suite (MuJoCo). A cart (1 kg) slides on a rail along x (x = 0 in the middle, stops at x = +-1.8 m); a pole…A cart-pole from the DeepMind Control Suite (MuJoCo). A cart (1 kg) slides on a rail along x (x = 0 in the middle, stops at x = +-1.8 m); a pole (1 m long, 0.1 kg) swings freely on an unactuated hinge on the cart, in the x-z plane (z up). pole_angle is in radians: 0 = pointing straight up, +-pi = hanging straight down; a positive angle tilts the top of the pole towards +x. The fixed camera looks along +y, so +x is to the right in the image. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,500 stepsends when first reached
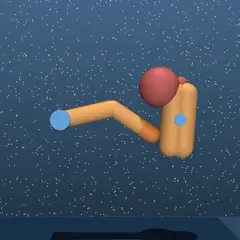
dmcontrol-finger-turn-easyThe finger domain of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, no gravity). A two-link finger is mounted on a hinge at (x, z)…The finger domain of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, no gravity). A two-link finger is mounted on a hinge at (x, z) = (-0.2, 0.4): the proximal link is 0.18 m long; the distal link ends in a rounded fingertip whose far end is 0.161 m from the distal joint (fingertip radius 3 cm). Both joints are damped and limited to +-110 degrees (+-1.92 rad). Angles are in radians: proximal_angle is the proximal link's direction measured counter-clockwise from +x in the x-z plane (0 = pointing towards +x, -pi/2 = pointing down), distal_angle the distal link's angle relative to it. The spinner is a free body on an unactuated, damped hinge at (0.2, 0.4): a bar 0.26 m long and 0.12 m wide made of two capsules, which stops turning almost at once when nothing pushes it. One end is marked: its tip (spinner_tip_pos) lies 0.13 m from the hinge. The target is a point on the same 0.13 m circle (target_pos). Only the fingertip and the proximal link collide; the finger can reach the spinner only on its left side. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
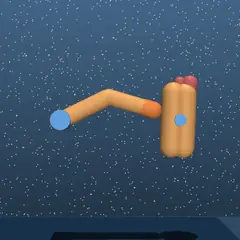
dmcontrol-finger-turn-hardThe finger domain of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, no gravity). A two-link finger is mounted on a hinge at (x, z)…The finger domain of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, no gravity). A two-link finger is mounted on a hinge at (x, z) = (-0.2, 0.4): the proximal link is 0.18 m long; the distal link ends in a rounded fingertip whose far end is 0.161 m from the distal joint (fingertip radius 3 cm). Both joints are damped and limited to +-110 degrees (+-1.92 rad). Angles are in radians: proximal_angle is the proximal link's direction measured counter-clockwise from +x in the x-z plane (0 = pointing towards +x, -pi/2 = pointing down), distal_angle the distal link's angle relative to it. The spinner is a free body on an unactuated, damped hinge at (0.2, 0.4): a bar 0.26 m long and 0.12 m wide made of two capsules, which stops turning almost at once when nothing pushes it. One end is marked: its tip (spinner_tip_pos) lies 0.13 m from the hinge. The target is a point on the same 0.13 m circle (target_pos). Only the fingertip and the proximal link collide; the finger can reach the spinner only on its left side. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
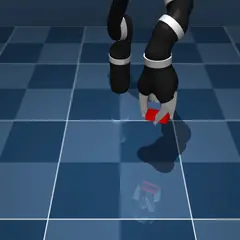
dmcontrol-jaco-lift-brickA Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from…A Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from dm_control.manipulation (MuJoCo). World frame in metres, z up, the table top at z = 0. The hand is controlled at its pinch point, the point between the fingertips (dm_control's tool centre point), and always points straight down; you set its position and its yaw (turn about the vertical). The objects are Duplo 2x4 bricks (6.4 x 3.2 cm, 1.9 cm tall plus studs); a brick's _pos is the centre of its bottom face and _yaw_deg the direction of its long side. The fingers close along the hand's yaw direction: with hand_yaw_deg at a brick's yaw + 90 degrees they grip the brick across its 3.2 cm width. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies600 stepsends when first reached
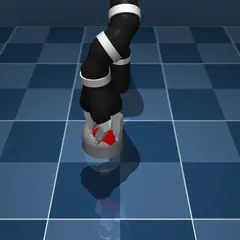
dmcontrol-jaco-place-brickA Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from…A Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from dm_control.manipulation (MuJoCo). World frame in metres, z up, the table top at z = 0. The hand is controlled at its pinch point, the point between the fingertips (dm_control's tool centre point), and always points straight down; you set its position and its yaw (turn about the vertical). The objects are Duplo 2x4 bricks (6.4 x 3.2 cm, 1.9 cm tall plus studs); a brick's _pos is the centre of its bottom face and _yaw_deg the direction of its long side. The fingers close along the hand's yaw direction: with hand_yaw_deg at a brick's yaw + 90 degrees they grip the brick across its 3.2 cm width. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies800 stepsends when first reached
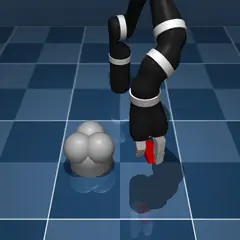
dmcontrol-jaco-place-cradleA Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from…A Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from dm_control.manipulation (MuJoCo). World frame in metres, z up, the table top at z = 0. The hand is controlled at its pinch point, the point between the fingertips (dm_control's tool centre point), and always points straight down; you set its position and its yaw (turn about the vertical). The objects are Duplo 2x4 bricks (6.4 x 3.2 cm, 1.9 cm tall plus studs); a brick's _pos is the centre of its bottom face and _yaw_deg the direction of its long side. The fingers close along the hand's yaw direction: with hand_yaw_deg at a brick's yaw + 90 degrees they grip the brick across its 3.2 cm width. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies800 stepsends when first reached
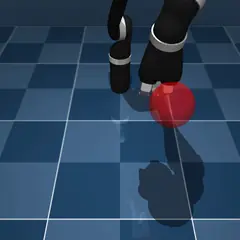
dmcontrol-jaco-reach-siteA Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from…A Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from dm_control.manipulation (MuJoCo). World frame in metres, z up, the table top at z = 0. The hand is controlled at its pinch point, the point between the fingertips (dm_control's tool centre point), and always points straight down; you set its position and its yaw (turn about the vertical). The objects are Duplo 2x4 bricks (6.4 x 3.2 cm, 1.9 cm tall plus studs); a brick's _pos is the centre of its bottom face and _yaw_deg the direction of its long side. The fingers close along the hand's yaw direction: with hand_yaw_deg at a brick's yaw + 90 degrees they grip the brick across its 3.2 cm width. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies300 stepsends when first reached
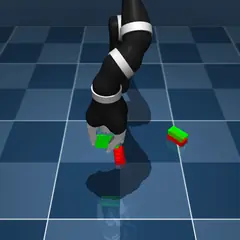
dmcontrol-jaco-stack-2-bricksA Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from…A Kinova Jaco robot arm (6 joints) with the three-finger Jaco hand stands at the edge of a table, its base at (0, 0.4, 0), from dm_control.manipulation (MuJoCo). World frame in metres, z up, the table top at z = 0. The hand is controlled at its pinch point, the point between the fingertips (dm_control's tool centre point), and always points straight down; you set its position and its yaw (turn about the vertical). The objects are Duplo 2x4 bricks (6.4 x 3.2 cm, 1.9 cm tall plus studs); a brick's _pos is the centre of its bottom face and _yaw_deg the direction of its long side. The fingers close along the hand's yaw direction: with hand_yaw_deg at a brick's yaw + 90 degrees they grip the brick across its 3.2 cm width. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
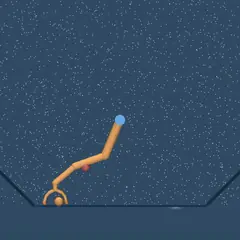
dmcontrol-manipulator-bring-ballThe planar manipulator of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, gravity on). An arm is mounted on a hinge at (x, z) = (0,…The planar manipulator of the DeepMind Control Suite (MuJoCo), in the x-z plane (z up, gravity on). An arm is mounted on a hinge at (x, z) = (0, 0.4) above a floor (z = 0) that is bounded by walls sloping up from x = +-0.4 m. Links: 0.18 m (root to shoulder), 0.15 m (shoulder to elbow), 0.12 m (elbow to wrist); the hand's grasp point (grasp_site_pos) is 0.065 m past the wrist and the pinch point between the fingertips 0.09 m. Joint angles are in radians; each joint turns about -y, so with 0 every link points straight up and a positive angle turns it towards -x: the direction of link k is (-sin Q, cos Q) with Q the sum of the joint angles up to it. arm_root turns without limit; arm_shoulder and arm_elbow are limited to +-160 degrees, arm_wrist to +-140 degrees. The hand has a thumb and a finger. A ball (2.2 cm radius) starts somewhere in the arena, possibly moving; it rolls freely on the floor. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies2,000 stepsends when first reached
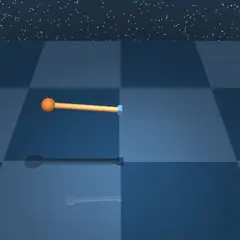
dmcontrol-pendulum-swingupA torque-limited pendulum from the DeepMind Control Suite (MuJoCo): a 1 kg ball on a 0.5 m massless rod, swinging in the x-z plane (z up) about a…A torque-limited pendulum from the DeepMind Control Suite (MuJoCo): a 1 kg ball on a 0.5 m massless rod, swinging in the x-z plane (z up) about a hinge with light damping. pole_angle is in radians: 0 = pointing straight up, +-pi = hanging straight down; a positive angle tilts the ball towards +x. The motor is too weak to lift the pendulum directly (gravity's torque reaches 4.9 N m, the motor gives at most 1 N m), so it has to be swung up. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies1,000 stepsends when first reached
dmcontrol-point-mass-easyA point mass from the DeepMind Control Suite (MuJoCo): a 0.3 kg ball (1 cm radius) slides on a table (the x-y plane, z up) inside a square arena…A point mass from the DeepMind Control Suite (MuJoCo): a 0.3 kg ball (1 cm radius) slides on a table (the x-y plane, z up) inside a square arena with walls at x, y = +-0.3 m. The target is a small sphere at the origin. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies500 stepsends when first reached
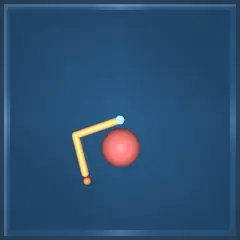
dmcontrol-reacher-easyA planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x,…A planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x, y = +-0.3 m. The shoulder is at the origin and turns without limit; the upper link is 0.12 m long, the wrist (range +-160 degrees) carries a 0.12 m link ending in the fingertip (a 1 cm sphere). Angles are in radians, counter-clockwise seen from above: shoulder_angle is the upper link's direction from +x, wrist_angle the lower link's angle relative to the upper link. The links are light, so the torques are small. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies500 stepsends when first reached
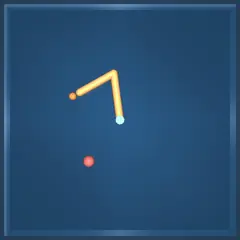
dmcontrol-reacher-hardA planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x,…A planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x, y = +-0.3 m. The shoulder is at the origin and turns without limit; the upper link is 0.12 m long, the wrist (range +-160 degrees) carries a 0.12 m link ending in the fingertip (a 1 cm sphere). Angles are in radians, counter-clockwise seen from above: shoulder_angle is the upper link's direction from +x, wrist_angle the lower link's angle relative to the upper link. The links are light, so the torques are small. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies500 stepsends when first reached
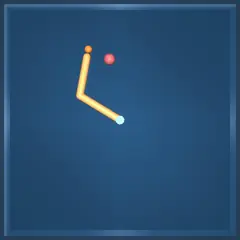
dmcontrol-reacher-hard-bA planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x,…A planar two-link arm from the DeepMind Control Suite (MuJoCo) lies flat on a table (the x-y plane, z up), inside a square arena with walls at x, y = +-0.3 m. The shoulder is at the origin and turns without limit; the upper link is 0.12 m long, the wrist (range +-160 degrees) carries a 0.12 m link ending in the fingertip (a 1 cm sphere). Angles are in radians, counter-clockwise seen from above: shoulder_angle is the upper link's direction from +x, wrist_angle the lower link's angle relative to the upper link. The links are light, so the torques are small. Simulated time advances only when you act; the scene is paused while you think. A feedback controller can run as a script: Python 3 with numpy is available, and robo observe --json / robo act ... --json print machine-readable output.
DeepMind Control Suite bodies500 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.