isaac-sim/isaaclab-factory
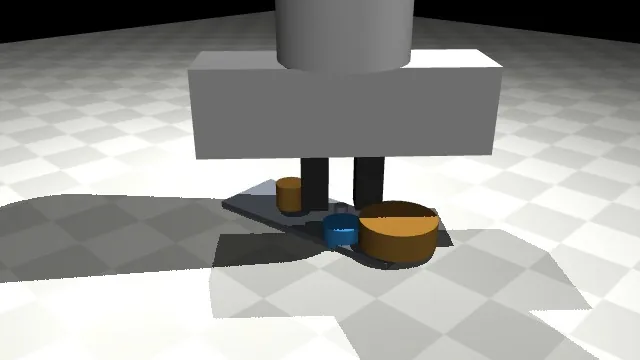
Contact-rich assembly from Isaac Lab's Factory on a Franka Panda.
robouse run-many \
  --tasks tasks/gpu-isaaclab \
  --harness oracle \
--out runs/gpu-isaaclab-oracleAbout this dataset
- Embodiment
- Franka Panda
- Simulator
- Isaac Lab 2.3 Factory (Isaac Sim 5.1)
- Requirements
- NVIDIA RTX GPU ·
bench>=0.7.4,<0.8 · runs from a Robo Use checkout - Licence
- Task packages Apache-2.0; adapted from Isaac Lab Factory by NVIDIA Isaac Sim (isaac-sim), BSD-3-Clause (Isaac Lab); Isaac Sim under the NVIDIA Isaac Sim additional software license
@misc{robouse_isaac_sim_isaaclab_factory_0_1,
  title        = {Robo Use isaac-sim/isaaclab-factory 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/isaac-sim/isaaclab-factory/}},
  note         = {BenchFlow dataset, tag isaac-sim/isaaclab-factory-v0.1, commit 9ad3e1a903c6; adapted from Isaac Lab Factory (NVIDIA Isaac Sim (isaac-sim))}
}5 tasks
Size
Step budget
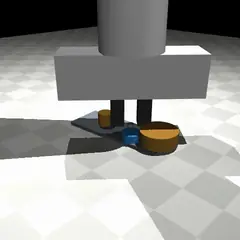
il-factory-gear-meshThe robot holds a medium gear above a gear base that already carries a small and a large gear. Put the medium gear onto its own shaft (the middle…The robot holds a medium gear above a gear base that already carries a small and a large gear. Put the medium gear onto its own shaft (the middle one on the base) and push it down until it sits on the base, meshed with its neighbours. The task is solved when the gear's hub is within 2.5 mm of the shaft axis and within 1 mm of its seated height.
Franka Panda400 stepsjudged on the final state
il-factory-nut-threadThe robot holds an M16 nut just above an M16 bolt (thread pitch 2 mm). Screw the nut onto the bolt: centre it, then turn it clockwise (RZ, which…The robot holds an M16 nut just above an M16 bolt (thread pitch 2 mm). Screw the nut onto the bolt: centre it, then turn it clockwise (RZ, which in this task only turns clockwise: RZ = +1 is the fastest turn, RZ = -1 no turn) while pressing down. The task is solved (Factory's condition) when the nut's bottom face is within 2.5 mm of the bolt's axis, has come down to within 0.75 mm (0.375 pitch) above a point 1.5 pitches below the top of the thread, and the hand's yaw has turned past zero (the hand starts at about +105 degrees and turns clockwise).
Franka Panda600 stepsjudged on the final state
il-factory-nut-thread-noisyThe robot holds an M16 nut just above an M16 bolt (thread pitch 2 mm). Screw the nut onto the bolt: centre it, then turn it clockwise (RZ, which…The robot holds an M16 nut just above an M16 bolt (thread pitch 2 mm). Screw the nut onto the bolt: centre it, then turn it clockwise (RZ, which in this task only turns clockwise: RZ = +1 is the fastest turn, RZ = -1 no turn) while pressing down. The task is solved (Factory's condition) when the nut's bottom face is within 2.5 mm of the bolt's axis, has come down to within 0.75 mm (0.375 pitch) above a point 1.5 pitches below the top of the thread, and the hand's yaw has turned past zero (the hand starts at about +105 degrees and turns clockwise).
Franka Panda600 stepsjudged on the final state
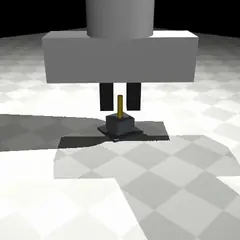
il-factory-peg-insertThe robot holds an 8 mm peg a few centimetres above a socket with an 8.1 mm hole (25 mm deep). Insert the peg into the hole and push it all the…The robot holds an 8 mm peg a few centimetres above a socket with an 8.1 mm hole (25 mm deep). Insert the peg into the hole and push it all the way down. The task is solved when the peg's base is within 2.5 mm of the hole's axis and within 1 mm of the bottom of the hole.
Franka Panda300 stepsjudged on the final state
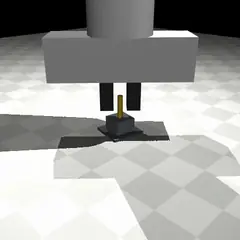
il-factory-peg-insert-noisyThe robot holds an 8 mm peg a few centimetres above a socket with an 8.1 mm hole (25 mm deep). Insert the peg into the hole and push it all the…The robot holds an 8 mm peg a few centimetres above a socket with an 8.1 mm hole (25 mm deep). Insert the peg into the hole and push it all the way down. The task is solved when the peg's base is within 2.5 mm of the hole's axis and within 1 mm of the bottom of the hole.
Franka Panda300 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9ad3e1a903c6. The verifier and the reference solution are not published.