mani-skill/maniskill
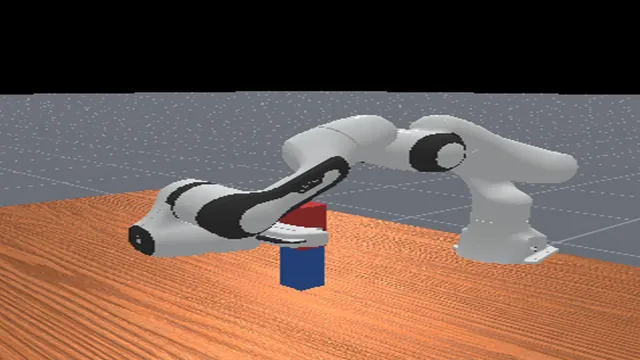
ManiSkill3 tabletop manipulation on a Franka Panda.
bench eval run \
  -d mani-skill/maniskill@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Franka Panda
- Simulator
- ManiSkill3 3.0.1 (SAPIEN 3.0.3, CPU)
- Requirements
- CPU only · 4 GB memory ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from ManiSkill3 by Hao Su Lab (UC San Diego) and Hillbot, Apache-2.0
@misc{robouse_mani_skill_maniskill_0_1,
  title        = {Robo Use mani-skill/maniskill 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/mani-skill/maniskill/}},
  note         = {BenchFlow dataset, tag mani-skill/maniskill-v0.1, commit bcd0d002b9df; adapted from ManiSkill3 (Hao Su Lab (UC San Diego) and Hillbot)}
}12 tasks
Size
Step budget
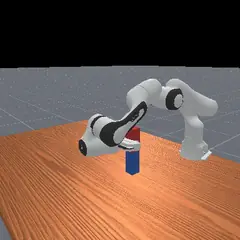
maniskill-lift-peg-uprightA peg (a 24 cm long, 5 cm square bar) lies on its side on the table. Stand it upright on one of its ends and let go.A peg (a 24 cm long, 5 cm square bar) lies on its side on the table. Stand it upright on one of its ends and let go.
Franka Panda500 stepsjudged on the final state
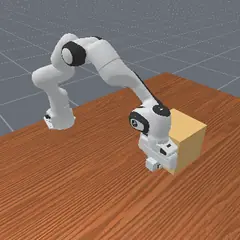
maniskill-peg-insertion-sidePick up the peg (a square bar, orange head end and white tail end) and insert its orange head end sideways into the hole in the box, at least…Pick up the peg (a square bar, orange head end and white tail end) and insert its orange head end sideways into the hole in the box, at least halfway in.
Franka Panda600 stepsjudged on the final state
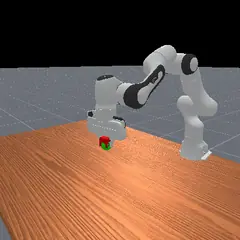
maniskill-pick-cubePick up the red cube (4 cm) and hold it so that its centre is at the goal point goal_pos, which floats in the air above the table (the green…Pick up the red cube (4 cm) and hold it so that its centre is at the goal point goal_pos, which floats in the air above the table (the green sphere in the images).
Franka Panda300 stepsjudged on the final state
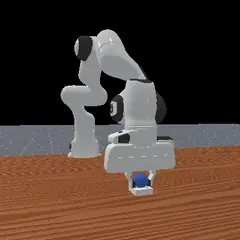
maniskill-place-spherePick up the blue ball (2 cm radius) and place it in the small square bin, then let go.Pick up the blue ball (2 cm radius) and place it in the small square bin, then let go.
Franka Panda300 stepsjudged on the final state
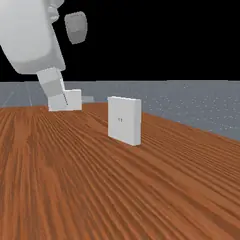
maniskill-plug-chargerPick up the charger (a small white block with two metal pins) and plug its pins into the wall receptacle that stands on the table.Pick up the charger (a small white block with two metal pins) and plug its pins into the wall receptacle that stands on the table.
Franka Panda600 stepsjudged on the final state
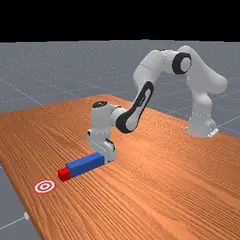
maniskill-poke-cubeGrasp the blue peg and use its head end to push the red cube into the red-and-white target region (radius 5 cm) centred at goal_pos.Grasp the blue peg and use its head end to push the red cube into the red-and-white target region (radius 5 cm) centred at goal_pos.
Franka Panda500 stepsjudged on the final state
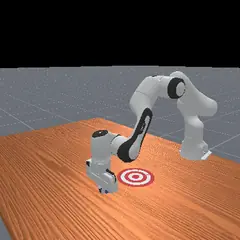
maniskill-pull-cubePull the blue cube along the table toward the robot into the red-and-white target region (radius 10 cm) centred at goal_pos, which lies behind…Pull the blue cube along the table toward the robot into the red-and-white target region (radius 10 cm) centred at goal_pos, which lies behind the cube (-x, on the robot's side).
Franka Panda300 stepsjudged on the final state
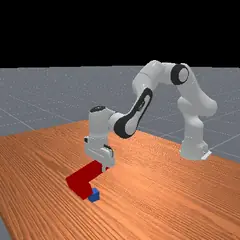
maniskill-pull-cube-toolThe blue cube lies out of comfortable reach. Grasp the red L-shaped tool and use its hook to pull the cube toward the robot's base until the cube…The blue cube lies out of comfortable reach. Grasp the red L-shaped tool and use its hook to pull the cube toward the robot's base until the cube is less than 0.6 m from the base.
Franka Panda500 stepsjudged on the final state
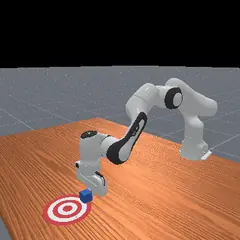
maniskill-push-cubePush the blue cube along the table into the red-and-white target region (radius 10 cm) centred at goal_pos, in front of it (+x).Push the blue cube along the table into the red-and-white target region (radius 10 cm) centred at goal_pos, in front of it (+x).
Franka Panda300 stepsjudged on the final state
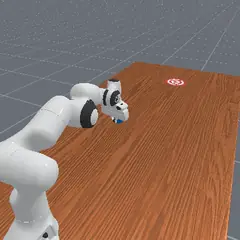
maniskill-roll-ballPush the blue ball (3.5 cm radius) so that it rolls across the table into the red-and-white target region (radius 10 cm) centred at goal_pos,…Push the blue ball (3.5 cm radius) so that it rolls across the table into the red-and-white target region (radius 10 cm) centred at goal_pos, more than a metre away, far out of the arm's reach.
Franka Panda300 stepsends when first reached
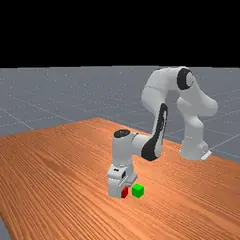
maniskill-stack-cubePick up the red cube and put it on top of the green cube (both 4 cm), then let go.Pick up the red cube and put it on top of the green cube (both 4 cm), then let go.
Franka Panda400 stepsjudged on the final state
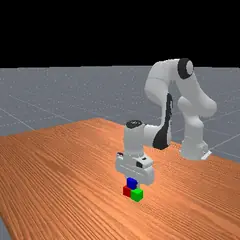
maniskill-stack-pyramidBuild a pyramid from the three 4 cm cubes: the red and green cubes side by side on the table, and the blue cube on top, resting on both.Build a pyramid from the three 4 cm cubes: the red and green cubes side by side on the table, and the blue cube on top, resting on both.
Franka Panda800 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.