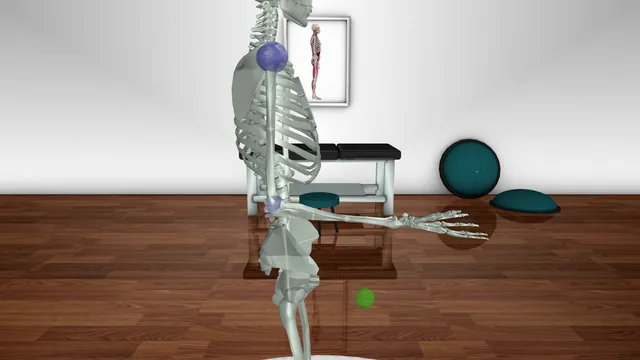
myohub/myosuite
Muscle-driven human arm and hand models from MyoSuite.
bench eval run \
  -d myohub/myosuite@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- MyoSuite musculoskeletal elbow, index finger and hand
- Simulator
- MyoSuite 2.12.2 (MuJoCo 3.6.0)
- Requirements
- CPU only · 2 GB memory ·
bench>=0.7.4,<0.8
@misc{robouse_myohub_myosuite_0_1,
  title        = {Robo Use myohub/myosuite 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/myohub/myosuite/}},
  note         = {BenchFlow dataset, tag myohub/myosuite-v0.1, commit bcd0d002b9df; adapted from MyoSuite (MyoHub)}
}15 tasks
Size
Step budget
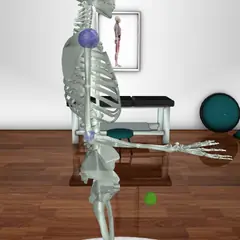
myosuite-elbow-poseYou control MyoElbow, MyoSuite's musculoskeletal model of a right arm (MuJoCo physics) with one joint, the elbow (r_elbow_flex: 0 rad = arm…You control MyoElbow, MyoSuite's musculoskeletal model of a right arm (MuJoCo physics) with one joint, the elbow (r_elbow_flex: 0 rad = arm straight, positive = flexed, range 0 to 2.27 rad), moved only by its 6 muscles: the three heads of the triceps (TRIlong, TRIlat, TRImed, which extend the elbow) and the biceps (BIClong, BICshort) and brachialis (BRA), which flex it. The upper arm is fixed; gravity pulls the forearm down. A muscle can only pull.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
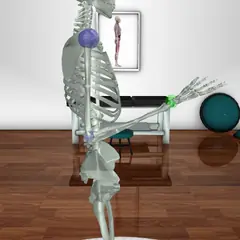
myosuite-elbow-pose-musclesYou control MyoElbow, MyoSuite's musculoskeletal model of a right arm (MuJoCo physics) with one joint, the elbow (r_elbow_flex: 0 rad = arm…You control MyoElbow, MyoSuite's musculoskeletal model of a right arm (MuJoCo physics) with one joint, the elbow (r_elbow_flex: 0 rad = arm straight, positive = flexed, range 0 to 2.27 rad), moved only by its 6 muscles: the three heads of the triceps (TRIlong, TRIlat, TRImed, which extend the elbow) and the biceps (BIClong, BICshort) and brachialis (BRA), which flex it. The upper arm is fixed; gravity pulls the forearm down. A muscle can only pull.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
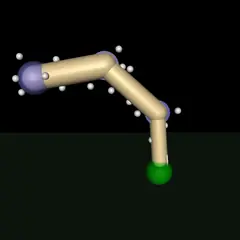
myosuite-finger-pose-fixedYou control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor),…You control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor), adabR and adabL (sideways, abduction/adduction), mflx and dflx (flexors). The finger's base is fixed; it has 4 joints: IFadb (sideways, -0.44 to 0.44 rad), IFmcp (knuckle flexion, -0.44 to 1.05 rad), IFpip and IFdip (middle and end joint flexion, 0 to 1.05 rad). Angles are in radians. The finger starts straight (all joints 0), pointing along +x; flexing bends it towards -z. World frame in metres, +z up. A muscle can only pull, and the flexors cross several joints.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
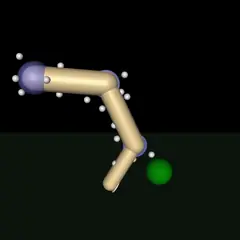
myosuite-finger-pose-musclesYou control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor),…You control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor), adabR and adabL (sideways, abduction/adduction), mflx and dflx (flexors). The finger's base is fixed; it has 4 joints: IFadb (sideways, -0.44 to 0.44 rad), IFmcp (knuckle flexion, -0.44 to 1.05 rad), IFpip and IFdip (middle and end joint flexion, 0 to 1.05 rad). Angles are in radians. The finger starts straight (all joints 0), pointing along +x; flexing bends it towards -z. World frame in metres, +z up. A muscle can only pull, and the flexors cross several joints.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
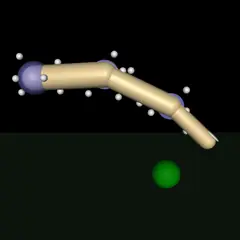
myosuite-finger-pose-randomYou control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor),…You control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor), adabR and adabL (sideways, abduction/adduction), mflx and dflx (flexors). The finger's base is fixed; it has 4 joints: IFadb (sideways, -0.44 to 0.44 rad), IFmcp (knuckle flexion, -0.44 to 1.05 rad), IFpip and IFdip (middle and end joint flexion, 0 to 1.05 rad). Angles are in radians. The finger starts straight (all joints 0), pointing along +x; flexing bends it towards -z. World frame in metres, +z up. A muscle can only pull, and the flexors cross several joints.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
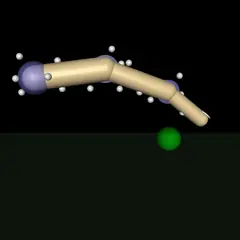
myosuite-finger-reach-fixedYou control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor),…You control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor), adabR and adabL (sideways, abduction/adduction), mflx and dflx (flexors). The finger's base is fixed; it has 4 joints: IFadb (sideways, -0.44 to 0.44 rad), IFmcp (knuckle flexion, -0.44 to 1.05 rad), IFpip and IFdip (middle and end joint flexion, 0 to 1.05 rad). Angles are in radians. The finger starts straight (all joints 0), pointing along +x; flexing bends it towards -z. World frame in metres, +z up. A muscle can only pull, and the flexors cross several joints.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
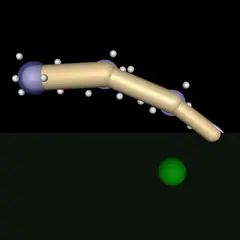
myosuite-finger-reach-randomYou control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor),…You control MyoFinger, MyoSuite's musculoskeletal model of a single index finger (MuJoCo physics), only through its 5 muscles: extn (extensor), adabR and adabL (sideways, abduction/adduction), mflx and dflx (flexors). The finger's base is fixed; it has 4 joints: IFadb (sideways, -0.44 to 0.44 rad), IFmcp (knuckle flexion, -0.44 to 1.05 rad), IFpip and IFdip (middle and end joint flexion, 0 to 1.05 rad). Angles are in radians. The finger starts straight (all joints 0), pointing along +x; flexing bends it towards -z. World frame in metres, +z up. A muscle can only pull, and the flexors cross several joints.
MyoSuite musculoskeletal elbow, index finger and hand300 stepsjudged on the final state
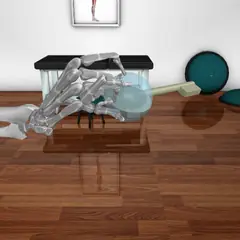
myosuite-hand-key-turnYou control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
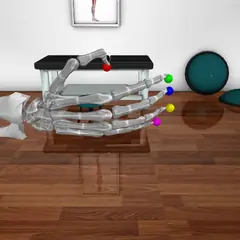
myosuite-hand-pose-4You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
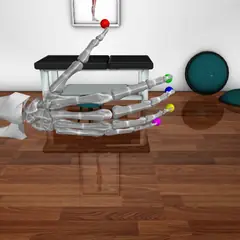
myosuite-hand-pose-5You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
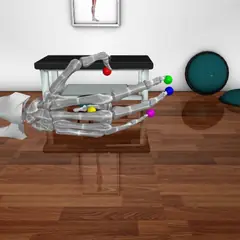
myosuite-hand-pose-7You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
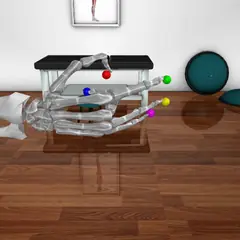
myosuite-hand-pose-8You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
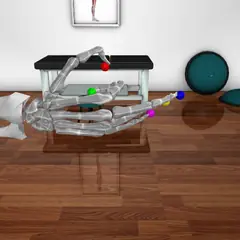
myosuite-hand-pose-9You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
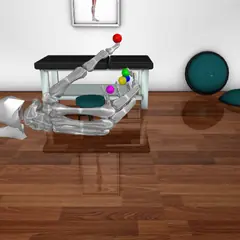
myosuite-hand-reach-fixedYou control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
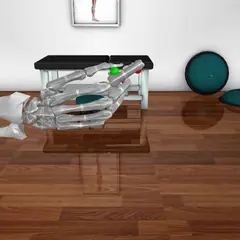
myosuite-hand-reach-randomYou control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The…You control MyoHand, MyoSuite's musculoskeletal model of a right human hand and forearm (MuJoCo physics), only through its 39 muscles. The forearm is fixed in space. 23 joints move: the wrist (pro_sup pronation/supination, deviation, flexion), the thumb (cmc_abduction, cmc_flexion, mp_flexion, ip_flexion) and the four fingers, numbered 2 = index, 3 = middle, 4 = ring, 5 = little, each with mcpN_flexion and mcpN_abduction (knuckle), pmN_flexion (middle joint) and mdN_flexion (end joint). Joint angles are in radians; robo info lists each joint's range under joint_ranges_rad. The muscles are the forearm muscles of the wrist and fingers (e.g. ECRL, FCU, FDS2..FDS5, FDP2..FDP5, EDC2..EDC5, FPL, EPL, APL) and the small hand muscles (OP, and per finger RI, LU_RB, UI_UB interossei/lumbricals). A muscle can only pull, many muscles cross several joints, and the fingers collide with each other (contacts), so moving one joint tends to move others. World frame in metres, +z up; the fingers point roughly along -y.
MyoSuite musculoskeletal elbow, index finger and hand500 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.