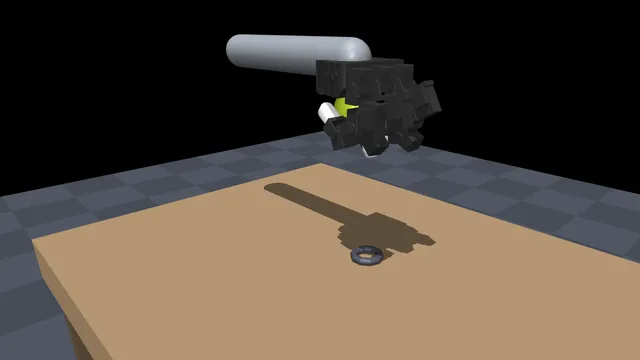
benchflow/dexhand
In-hand manipulation with the Shadow Hand and LEAP Hand.
bench eval run \
  -d benchflow/dexhand@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Shadow Hand
- Simulator
- MuJoCo Menagerie models
- Requirements
- CPU only ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_dexhand_0_1,
  title        = {Robo Use benchflow/dexhand 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/dexhand/}},
  note         = {BenchFlow dataset, tag benchflow/dexhand-v0.1, commit bcd0d002b9df}
}7 tasks
Size
Step budget
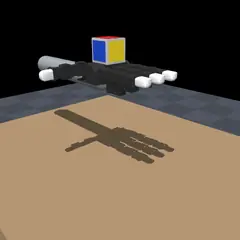
leap-cube-in-handYou control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring…You control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring fingers have mcp, rot (side-to-side), pip and dip joints, the thumb has cmc, axl, mcp and ipl). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand600 stepsjudged on the final state
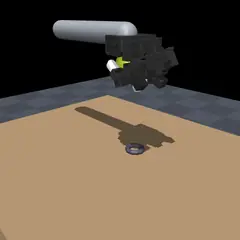
leap-lift-ballYou control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring…You control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring fingers have mcp, rot (side-to-side), pip and dip joints, the thumb has cmc, axl, mcp and ipl). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand700 stepsjudged on the final state
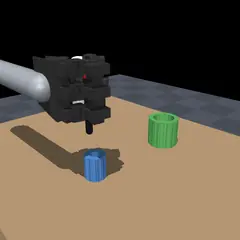
leap-pen-to-holderYou control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring…You control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring fingers have mcp, rot (side-to-side), pip and dip joints, the thumb has cmc, axl, mcp and ipl). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand1,000 stepsjudged on the final state
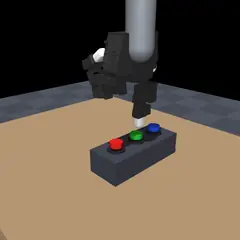
leap-press-buttonsYou control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring…You control a right LEAP Hand (MuJoCo Menagerie model leap_hand, MIT: 16 joints, each driven by its own position actuator; index, middle and ring fingers have mcp, rot (side-to-side), pip and dip joints, the thumb has cmc, axl, mcp and ipl). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand800 stepsjudged on the final state
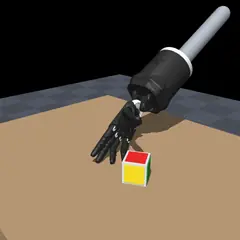
shadow-cube-face-upYou control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two…You control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two distal joints of each finger are coupled by a tendon, as on the real hand, and are driven together by one actuator ..J0 whose target is their sum). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand1,200 stepsjudged on the final state
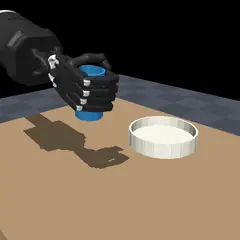
shadow-pour-ballsYou control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two…You control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two distal joints of each finger are coupled by a tendon, as on the real hand, and are driven together by one actuator ..J0 whose target is their sum). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand1,200 stepsjudged on the final state
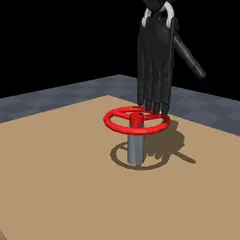
shadow-turn-valveYou control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two…You control a right Shadow Dexterous Hand (MuJoCo Menagerie model shadow_hand, Apache-2.0: 24 joints driven by 20 position actuators; the two distal joints of each finger are coupled by a tendon, as on the real hand, and are driven together by one actuator ..J0 whose target is their sum). Like a hand in a lab setup that is carried by a robot arm or gantry, it hangs from a 6-axis positioner above a table: three linear axes move the wrist in x, y and z and three rotary axes turn it in yaw, pitch and roll. The hand is not fixed to anything else and has no other support. World frame in metres: +x forward (away from the positioner's home), +y to the left, +z up; the floor is at z = 0 and the table top is at z = 0.40, spanning x from -0.35 to 0.55 and y from -0.35 to 0.35. At roll = pitch = yaw = 0 the palm faces down and the fingers point along +x. PITCH tips the fingers down (+) or up (-); ROLL turns the hand about its own long axis (+90 makes the palm face +y, 180 makes it face up); YAW turns it about the vertical (counter-clockwise seen from above is +). hand.palm_pos is a point about 3.5 cm in front of the palm, roughly where a grasped object sits. Objects are real rigid bodies with rubber-like friction: a grasp holds only as long as the fingers' contact forces and friction hold it, and anything dropped falls. An object that falls to the floor fails the task.
Shadow Hand1,000 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.