benchflow/driving
Traffic scenarios for a sedan on MetaDrive roads.
bench eval run \
  -d benchflow/driving@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- MetaDrive sedan
- Simulator
- MetaDrive 0.4.3
- Requirements
- CPU only ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_driving_0_1,
  title        = {Robo Use benchflow/driving 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/driving/}},
  note         = {BenchFlow dataset, tag benchflow/driving-v0.1, commit bcd0d002b9df}
}7 tasks
Size
Step budget
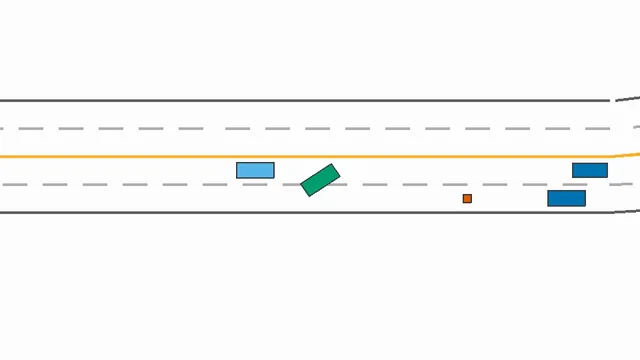
driving-broken-down-carYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan800 stepsjudged on the final state
driving-cone-zoneYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan900 stepsjudged on the final state
driving-highway-overtakeYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan500 stepsjudged on the final state
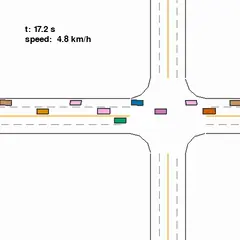
driving-intersection-left-turnYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan900 stepsjudged on the final state
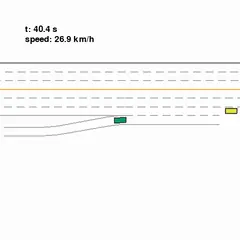
driving-ramp-mergeYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan800 stepsjudged on the final state
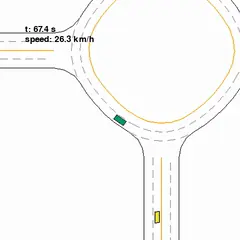
driving-roundaboutYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan1,200 stepsjudged on the final state
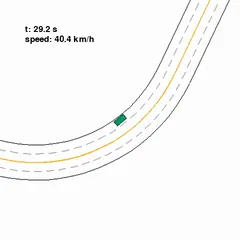
driving-winding-roadYou drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road…You drive a passenger car (MetaDrive's default sedan: 4.5 m long, 1.85 m wide, Bullet vehicle dynamics, no engine force above 80 km/h) on a road map built by the MetaDrive driving simulator. Map frame in metres: x, y on the ground, heading_deg 0 along +x and counter-clockwise positive; the top-down camera shows +y up. Traffic drives on the right. The two directions of a road are separated by a solid yellow centre line (drawn yellow in the top-down view), which you must never touch or cross. Lanes of your direction are numbered from the left: lane 0 is the one next to the yellow centre line. Roads are named by MetaDrive node pairs (e.g. >>>->1S0_0_). The navigation route is fixed: robo observe gives, under route, the distance travelled and remaining, the next roads (distance to their start, lane count and shape: straight, or a curve with its radius and turn angle) and the destination. Road users within 60 m are listed under vehicles and road objects (cones, warning triangles, barriers) under obstacles, with their position in your car's frame, their distance along your route and their lane. Other drivers follow MetaDrive's car-following model: they brake for what is ahead in their lane, but they do not yield to you at junctions and do not make room when you cut in. Simulated time advances only when you act; the scene is paused while you think.
MetaDrive sedan1,000 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.