benchflow/humanoid
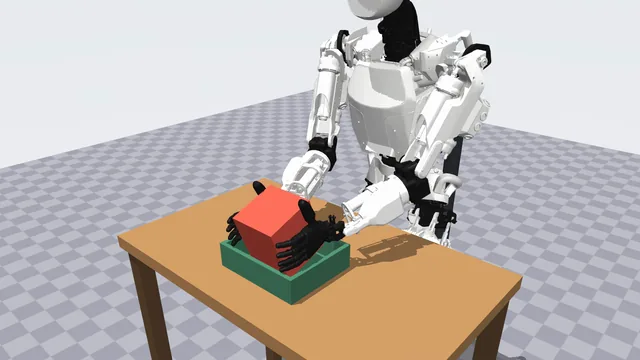
Humanoids on support stands doing tabletop tasks: Unitree G1 and H1, Apptronik Apollo and Booster T1.
robouse run-many \
  --tasks "$(robouse tasks --path)/humanoid" \
  --harness claude-code \
--out runs/humanoidAbout this dataset
- Embodiment
- Unitree G1, Apptronik Apollo
- Simulator
- MuJoCo Menagerie models
- Needs
pip install 'robouse[sim]', thenrobouse fetch-assets --all- Release
- Robo Use 0.6.1, suite
humanoid - Licence
- Task text and reference solutions Apache-2.0 (Robo Use)
9 tasks
Embodiment
Budget
Budget
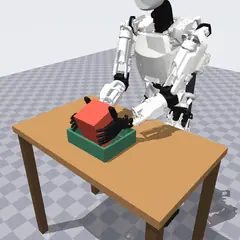
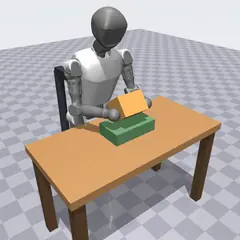
Put the red box into the green bin.
Apptronik Apollo700 stepsjudged on the final state
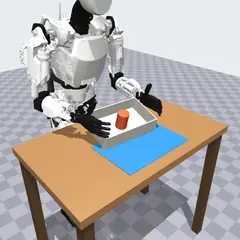
apollo-carry-trayCarry the tray, with the cup still standing in it, onto the blue mat.Carry the tray, with the cup still standing in it, onto the blue mat.
Apptronik Apollo700 stepsjudged on the final state
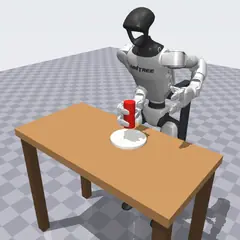
Pick up the red can and stand it on the white plate.
Unitree G1500 stepsjudged on the final state
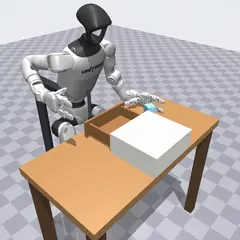
Put the soap into the drawer and close the drawer.
Unitree G11,200 stepsjudged on the final state
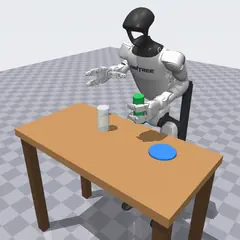
Get the green bottle standing on the blue coaster.
Unitree G1900 stepsjudged on the final state
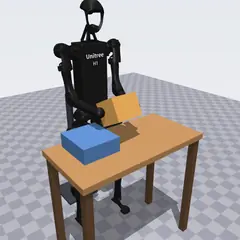
h1-box-to-shelfMove the box onto the top of the blue shelf block.Move the box onto the top of the blue shelf block.
Unitree G1700 stepsjudged on the final state
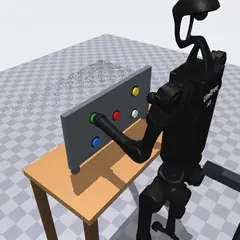
h1-panel-sequencePress the buttons in this order: yellow, green, white, blue. Do not press the red emergency-stop button.Press the buttons in this order: yellow, green, white, blue. Do not press the red emergency-stop button.
Unitree G1600 stepsjudged on the final state
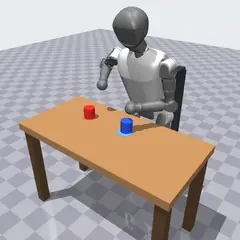
t1-push-cansPush the red can into the red zone and the blue can into the blue zone.Push the red can into the red zone and the blue can into the blue zone.
Unitree G1700 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a folder in the task format, in tasks/humanoid/ of Robo Use 0.6.1. The task text is shown here; the reference solution and the verifier are on GitHub.