benchflow/mobile-manip
Fetch, stow and sort in a three-room apartment.
bench eval run \
  -d benchflow/mobile-manip@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Hello Robot Stretch 3
- Simulator
- MuJoCo Menagerie models
- Requirements
- CPU only ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_mobile_manip_0_1,
  title        = {Robo Use benchflow/mobile-manip 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/mobile-manip/}},
  note         = {BenchFlow dataset, tag benchflow/mobile-manip-v0.1, commit bcd0d002b9df}
}10 tasks
Size
Step budget
google-fetch-canYou control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a…You control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a mobile base. Its Menagerie model has no mobile-base joints (the real robot drives on two wheels), so this suite adds a planar base: x, y and yaw joints on the robot's root, driven by force-limited velocity actuators. This is a holonomic abstraction: the base can move sideways, which the real robot cannot, and its wheels hover 3 mm above the floor. The base is about 0.75 m long (0.45 m of it behind the base centre) and 0.8 m wide. The gripper reaches about 0.55 to 0.9 m in front of the base centre, from about 0.45 m to 1.2 m high.
Hello Robot Stretch 32,600 stepsjudged on the final state
google-open-drawerYou control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a…You control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a mobile base. Its Menagerie model has no mobile-base joints (the real robot drives on two wheels), so this suite adds a planar base: x, y and yaw joints on the robot's root, driven by force-limited velocity actuators. This is a holonomic abstraction: the base can move sideways, which the real robot cannot, and its wheels hover 3 mm above the floor. The base is about 0.75 m long (0.45 m of it behind the base centre) and 0.8 m wide. The gripper reaches about 0.55 to 0.9 m in front of the base centre, from about 0.45 m to 1.2 m high.
Hello Robot Stretch 31,400 stepsjudged on the final state
google-sort-bottle-canYou control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a…You control the Google Robot (MuJoCo Menagerie google_robot, Apache-2.0): a 7-joint arm with a two-finger gripper (opens to about 12 cm) on a mobile base. Its Menagerie model has no mobile-base joints (the real robot drives on two wheels), so this suite adds a planar base: x, y and yaw joints on the robot's root, driven by force-limited velocity actuators. This is a holonomic abstraction: the base can move sideways, which the real robot cannot, and its wheels hover 3 mm above the floor. The base is about 0.75 m long (0.45 m of it behind the base centre) and 0.8 m wide. The gripper reaches about 0.55 to 0.9 m in front of the base centre, from about 0.45 m to 1.2 m high.
Hello Robot Stretch 33,600 stepsjudged on the final state
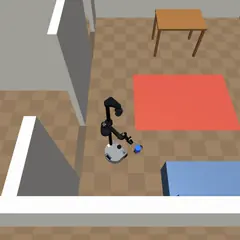
stretch-fetch-cupYou control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that…You control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that moves along a vertical mast, and a telescoping arm that sticks out to the robot's right (the -y side of the robot frame) with a wrist (yaw, pitch) and a two-finger gripper with rubber fingertips (opens to about 16 cm). The arm works in the vertical plane through the base centre perpendicular to the heading: to reach something, park with the robot's right side towards it, 0.40 to 0.91 m away (grasp heights 0.11 to 1.21 m). The upstream model's wheel speed limit is raised from 0.1 to 0.25 m/s, close to the real robot's driving speed; everything else (masses, joints, actuators) is upstream.
Hello Robot Stretch 34,000 stepsjudged on the final state
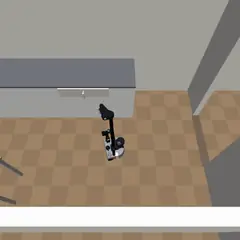
stretch-open-drawerYou control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that…You control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that moves along a vertical mast, and a telescoping arm that sticks out to the robot's right (the -y side of the robot frame) with a wrist (yaw, pitch) and a two-finger gripper with rubber fingertips (opens to about 16 cm). The arm works in the vertical plane through the base centre perpendicular to the heading: to reach something, park with the robot's right side towards it, 0.40 to 0.91 m away (grasp heights 0.11 to 1.21 m). The upstream model's wheel speed limit is raised from 0.1 to 0.25 m/s, close to the real robot's driving speed; everything else (masses, joints, actuators) is upstream.
Hello Robot Stretch 32,400 stepsjudged on the final state
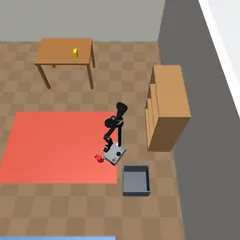
stretch-shelve-twoYou control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that…You control a Hello Robot Stretch 3 (MuJoCo Menagerie hello_robot_stretch_3, Apache-2.0): a differential-drive base 0.34 m wide, a lift that moves along a vertical mast, and a telescoping arm that sticks out to the robot's right (the -y side of the robot frame) with a wrist (yaw, pitch) and a two-finger gripper with rubber fingertips (opens to about 16 cm). The arm works in the vertical plane through the base centre perpendicular to the heading: to reach something, park with the robot's right side towards it, 0.40 to 0.91 m away (grasp heights 0.11 to 1.21 m). The upstream model's wheel speed limit is raised from 0.1 to 0.25 m/s, close to the real robot's driving speed; everything else (masses, joints, actuators) is upstream.
Hello Robot Stretch 35,000 stepsjudged on the final state
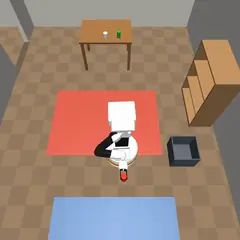
tiago-bin-cansYou control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and…You control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and a parallel two-finger gripper that opens to about 9 cm. The gripper reaches about 0.6 to 0.95 m in front of the base centre, from about 0.45 m to 1.2 m high. Each finger collides through a flat rubber pad on its inner face (the upstream finger meshes are kept for looks).
Hello Robot Stretch 34,000 stepsjudged on the final state
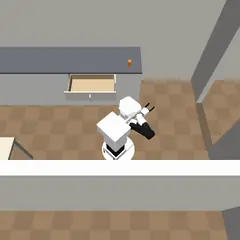
tiago-drawer-stowYou control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and…You control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and a parallel two-finger gripper that opens to about 9 cm. The gripper reaches about 0.6 to 0.95 m in front of the base centre, from about 0.45 m to 1.2 m high. Each finger collides through a flat rubber pad on its inner face (the upstream finger meshes are kept for looks).
Hello Robot Stretch 33,000 stepsjudged on the final state
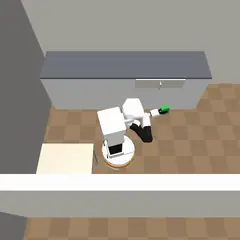
tiago-fetch-juiceYou control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and…You control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and a parallel two-finger gripper that opens to about 9 cm. The gripper reaches about 0.6 to 0.95 m in front of the base centre, from about 0.45 m to 1.2 m high. Each finger collides through a flat rubber pad on its inner face (the upstream finger meshes are kept for looks).
Hello Robot Stretch 33,600 stepsjudged on the final state
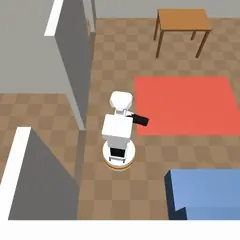
tiago-study-to-kitchenYou control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and…You control a PAL TIAGo (MuJoCo Menagerie pal_tiago, Apache-2.0): a round differential-drive base 0.54 m across, a torso lift, a 7-joint arm and a parallel two-finger gripper that opens to about 9 cm. The gripper reaches about 0.6 to 0.95 m in front of the base centre, from about 0.45 m to 1.2 m high. Each finger collides through a flat rubber pad on its inner face (the upstream finger meshes are kept for looks).
Hello Robot Stretch 33,600 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.