benchflow/quadruped
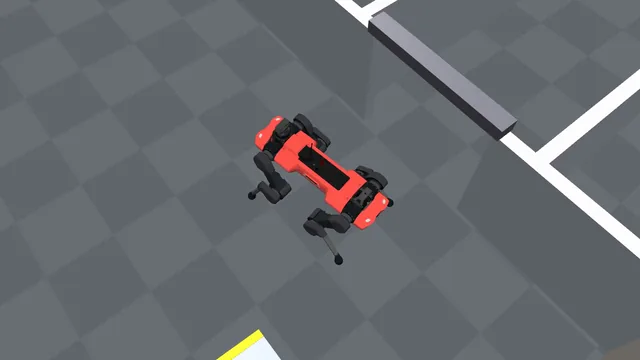
Unitree, Boston Dynamics and ANYbotics quadrupeds walking, pushing and docking.
bench eval run \
  -d benchflow/quadruped@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Unitree Go2
- Simulator
- MuJoCo Menagerie models
- Requirements
- CPU only ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_quadruped_0_1,
  title        = {Robo Use benchflow/quadruped 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/quadruped/}},
  note         = {BenchFlow dataset, tag benchflow/quadruped-v0.1, commit bcd0d002b9df}
}11 tasks
Task type
Size
Step budget
anymal-inspection-roundYou control an ANYbotics ANYmal C quadruped (MuJoCo Menagerie model, 45 kg, 1.0 m long, base about 0.47 m above the floor when standing) in a…You control an ANYbotics ANYmal C quadruped (MuJoCo Menagerie model, 45 kg, 1.0 m long, base about 0.47 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go22,400 stepsjudged on the final state
anymal-mezzanine-cabinetYou control an ANYbotics ANYmal C quadruped (MuJoCo Menagerie model, 45 kg, 1.0 m long, base about 0.47 m above the floor when standing) in a…You control an ANYbotics ANYmal C quadruped (MuJoCo Menagerie model, 45 kg, 1.0 m long, base about 0.47 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go21,200 stepsjudged on the final state
go1-corridor-chargerYou control a Unitree Go1 quadruped (MuJoCo Menagerie model, 13 kg, 0.65 m long, base about 0.27 m above the floor when standing) in a small…You control a Unitree Go1 quadruped (MuJoCo Menagerie model, 13 kg, 0.65 m long, base about 0.27 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go21,400 stepsjudged on the final state
go1-patrolYou control a Unitree Go1 quadruped (MuJoCo Menagerie model, 13 kg, 0.65 m long, base about 0.27 m above the floor when standing) in a small…You control a Unitree Go1 quadruped (MuJoCo Menagerie model, 13 kg, 0.65 m long, base about 0.27 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go22,400 stepsjudged on the final state
go2-crate-detourYou control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small…You control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go2900 stepsjudged on the final state
go2-crate-detour-manualYou control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small…You control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go2900 stepsjudged on the final state
go2-pump-inspectionYou control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small…You control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go21,400 stepsjudged on the final state
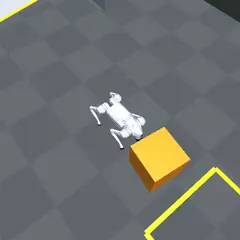
go2-push-boxYou control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small…You control a Unitree Go2 quadruped (MuJoCo Menagerie model, 15 kg, 0.7 m long, base about 0.29 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go21,200 stepsjudged on the final state
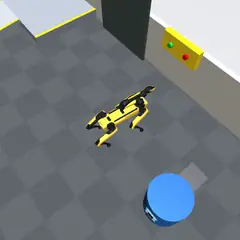
spot-arm-estopYou control a Boston Dynamics Spot quadruped with its 6-joint arm and gripper (MuJoCo Menagerie model, 56 kg, 1.1 m long, base about 0.47 m above…You control a Boston Dynamics Spot quadruped with its 6-joint arm and gripper (MuJoCo Menagerie model, 56 kg, 1.1 m long, base about 0.47 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go2900 stepsjudged on the final state
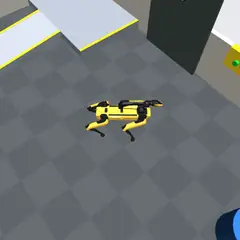
spot-arm-resetYou control a Boston Dynamics Spot quadruped with its 6-joint arm and gripper (MuJoCo Menagerie model, 56 kg, 1.1 m long, base about 0.47 m above…You control a Boston Dynamics Spot quadruped with its 6-joint arm and gripper (MuJoCo Menagerie model, 56 kg, 1.1 m long, base about 0.47 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go2900 stepsjudged on the final state
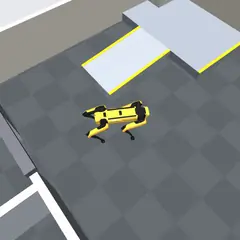
spot-gauge-readingYou control a Boston Dynamics Spot quadruped (MuJoCo Menagerie model, 50 kg, 1.1 m long, base about 0.47 m above the floor when standing) in a…You control a Boston Dynamics Spot quadruped (MuJoCo Menagerie model, 50 kg, 1.1 m long, base about 0.47 m above the floor when standing) in a small indoor plant. World frame in metres: +x east, +y north, +z up, floor at z = 0; headings are in degrees, 0 = facing +x (east), 90 = facing +y (north). The plant is 12 m x 8 m (x from -6 to 6, y from -4 to 4), closed by 1 m walls. A partition wall at x = 1 separates the west hall from the east plant room; its only opening is a 1.1 m wide doorway (y from 1.5 to 2.6) at the east end of a corridor (walls at y = 1.3 and y = 2.9, from x = -2.2 to the partition; open at its west end). The west hall has the blue dock (0.9 m square at (-4.8, -2.8)), a row of crates (0.6 m cubes, 0.8 m high, at x = -3.2 from y = -3.95 to -0.95) and one more crate at (-1.9, -1.1), a green mat at (-1.2, -2.8), and a pipe with a valve and an inspection tag on the west wall. The east room has a pump (radius 0.3 m, 0.6 m high, at (4.2, -2.6)) with an asset tag, an instrument board with a pressure gauge 1.4 m up on the east wall, a yellow panel with a red emergency-stop button and a green reset button on the east wall, and a 0.2 m high mezzanine platform in the north-east corner (x 4.4-6, y 1.6-4) with a control cabinet, reached by a ramp (x 2.8-4.4, y 2.4-3.4) that rises eastwards. Every fixed position is listed under facility in robo observe. The robot stands on a free-floating base: only its feet touching the floor move it, so it can slip, trip over obstacles or fall; a fall (base tilted more than 50 degrees, or the body touching the floor, the ramp or the platform) is recorded in safety_events and fails the task.
Unitree Go21,200 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.