Pick up the block and place it at the goal position
Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there
gymrobotics-fetch-pick-place-s0seed 0 variantGymnasium-RoboticsFetch armManipulationmedium
Instruction
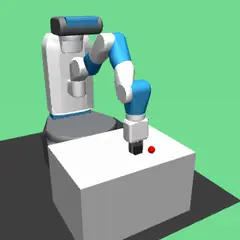
A Fetch robot arm with a two-finger parallel gripper stands at a table (adapted from Gymnasium-Robotics, FetchPickAndPlace-v4, layout seed 0).
Goal: Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there.
Success: the block centre (obj1_pos) is within 5 cm of goal_pos in 3-D, judged after you call robo done and the robot has held still for about 10 steps (keeping the gripper as it was).
In robo observe: hand_pos/hand_vel are the gripper position (m) and velocity (m/s), gripper_open is the finger opening (0 = closed, 1 = fully open) and gripper_width the gap in metres, obj1_pos, obj1_vel and obj1_rot (Euler angles, rad) describe the block, and goal_pos is the target (shown as a red sphere in camera images). The block is a 5 cm cube.
The action robo act DX DY DZ GRIP moves the gripper by up to 5 cm per step along world x/y/z (DX = 1 means 5 cm); GRIP +1 closes the fingers and -1 opens them. The gripper always points down.
How the robot is controlled and scored
You are controlling a simulated robot. Read the task below, then solve it by running the robo command in your shell (start with robo info and robo observe). Keep going until the task is done, then call robo done once. Do not stop to ask questions; there is no human to answer.
How to control the robot
You are the robot's policy. You act only through the robo command in your shell. There is no other way to move the robot, and you cannot read or change the simulator, the scoring, or other files to succeed; the episode server judges the final physical state itself.
robo info                         # action space, available skills, step budget
robo observe                      # robot and object state as numbers
robo observe --image              # also saves a camera image and prints its path (open it to look)
robo act DX DY DZ GRIP [--repeat N]   # low-level action, applied N times (N <= 50)
robo move-to X Y Z [--grip G]     # skill: move the gripper toward a point (if enabled for this task)
robo grip G [--steps N]           # skill: hold position and set the gripper (+1 close, -1 open)
robo done "short summary"         # end the episode and ask for scoring
robo give-up "reason" # end the episode without claiming success- Positions are in metres in the world frame (x, y on the table plane, z up).
- The episode has a fixed step budget (see
robo info); every simulated step counts, including skills. - Unless the task says otherwise, success is judged about 10 steps after you call
robo done, with the robot holding still, so the goal must still be true when the robot stops. - Work in small steps and re-observe after each motion. Call
robo doneexactly once when finished.
Run this task
bench eval run \
  -d benchflow/robouse-noop-control@0.2 \
  --registry https://robouse.ai/hub/registry.json \
  --agent oracle \
--include gymrobotics-fetch-pick-place-s0Pinned to robohub commit e472b1a1e041. The verifier and the reference solution are not published.
Model results for this scene: benchflow/robouse-core.