brave-eai/dexjoco
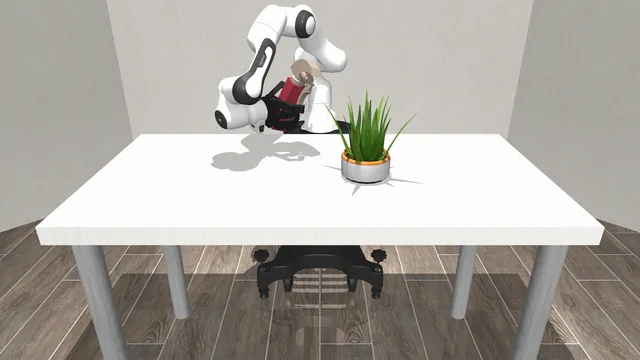
Tool use with Allegro hands on Franka arms, from DexJoCo.
robouse run-many \
  --tasks "$(robouse tasks --path)/dexjoco" \
  --harness claude-code \
--out runs/dexjocoAbout this dataset
- Embodiment
- Allegro hands on Franka arms
- Simulator
- DexJoCo (MuJoCo 3.4.0)
- Needs
pip install 'robouse[sim]', thenpip install 'robouse[dexjoco]'and DexJoCo's own virtualenv- Release
- Robo Use 0.6.1, suite
dexjoco
14 tasks
Budget
Budget
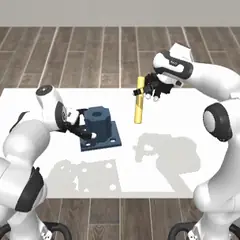
dexjoco-assemblyA round peg (8 mm across) and a socket block with a matching hole lie on the table. Pick them up and insert the peg fully into the socket's hole.A round peg (8 mm across) and a socket block with a matching hole lie on the table. Pick them up and insert the peg fully into the socket's hole.
Allegro hands on Franka arms3,000 stepsends when first reached
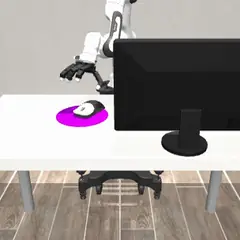
dexjoco-click-mouseA computer mouse lies on the table next to a monitor and a round mousepad. Move the mouse onto the mousepad and click its left button, which…A computer mouse lies on the table next to a monitor and a round mousepad. Move the mouse onto the mousepad and click its left button, which turns the monitor blue.
Allegro hands on Franka arms2,500 stepsends when first reached
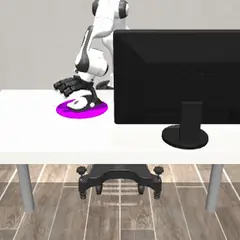
dexjoco-click-mouse-bA computer mouse lies on the table next to a monitor and a round mousepad. Move the mouse onto the mousepad and click its left button, which…A computer mouse lies on the table next to a monitor and a round mousepad. Move the mouse onto the mousepad and click its left button, which turns the monitor blue.
Allegro hands on Franka arms2,500 stepsends when first reached
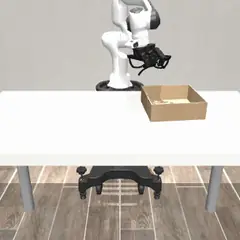
dexjoco-fold-glassesA pair of glasses lies open on the table next to an open box. Fold both temples (the arms of the glasses) shut and put the folded glasses into…A pair of glasses lies open on the table next to an open box. Fold both temples (the arms of the glasses) shut and put the folded glasses into the box.
Allegro hands on Franka arms2,500 stepsends when first reached
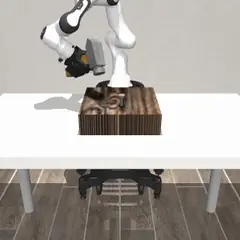
dexjoco-hammer-nailA hammer stands on the table and a nail sticks up out of a wooden block. Pick up the hammer by its handle and drive the nail into the wood by…A hammer stands on the table and a nail sticks up out of a wooden block. Pick up the hammer by its handle and drive the nail into the wood by striking its head.
Allegro hands on Franka arms2,500 stepsends when first reached
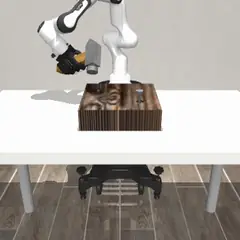
dexjoco-hammer-nail-bA hammer stands on the table and a nail sticks up out of a wooden block. Pick up the hammer by its handle and drive the nail into the wood by…A hammer stands on the table and a nail sticks up out of a wooden block. Pick up the hammer by its handle and drive the nail into the wood by striking its head.
Allegro hands on Franka arms2,500 stepsends when first reached
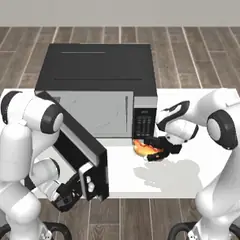
dexjoco-microwave-cookA microwave oven and a hot dog stand on the table. Open the microwave door, put the hot dog inside, close the door, and press the start button.A microwave oven and a hot dog stand on the table. Open the microwave door, put the hot dog inside, close the door, and press the start button.
Allegro hands on Franka arms3,000 stepsends when first reached
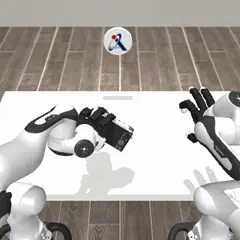
dexjoco-photographA compact camera lies on the table and a logo is displayed in front of the robots. Pick the camera up, aim it at the logo from the marked…A compact camera lies on the table and a logo is displayed in front of the robots. Pick the camera up, aim it at the logo from the marked shooting position, and press the shutter button.
Allegro hands on Franka arms3,000 stepsends when first reached
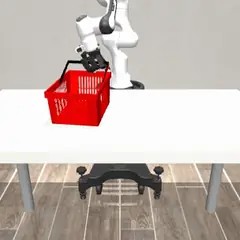
dexjoco-pick-bucketA small bucket with a swinging wire handle and a boxed food item stand on the table. Put the food box into the bucket, then lift the bucket by…A small bucket with a swinging wire handle and a boxed food item stand on the table. Put the food box into the bucket, then lift the bucket by its handle.
Allegro hands on Franka arms2,500 stepsends when first reached
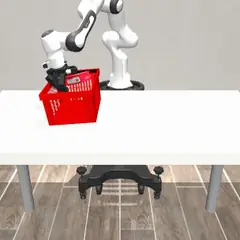
dexjoco-pick-bucket-bA small bucket with a swinging wire handle and a boxed food item stand on the table. Put the food box into the bucket, then lift the bucket by…A small bucket with a swinging wire handle and a boxed food item stand on the table. Put the food box into the bucket, then lift the bucket by its handle.
Allegro hands on Franka arms2,500 stepsends when first reached
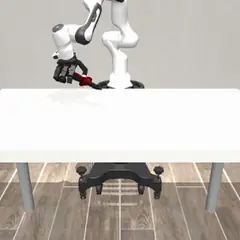
dexjoco-pinch-tongsA pair of kitchen tongs lies on the table. Pick them up, hold them at least 10 cm above the table, and squeeze them shut three times.A pair of kitchen tongs lies on the table. Pick them up, hold them at least 10 cm above the table, and squeeze them shut three times.
Allegro hands on Franka arms2,500 stepsends when first reached
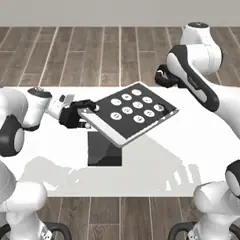
dexjoco-unlock-ipadAn iPad stands in a stand on the table, its lock screen facing the robots and showing a keypad of digit buttons. Enter the passcode 1, 2, 3 by…An iPad stands in a stand on the table, its lock screen facing the robots and showing a keypad of digit buttons. Enter the passcode 1, 2, 3 by pressing those digit buttons in that order with the fingertips.
Allegro hands on Franka arms3,000 stepsends when first reached
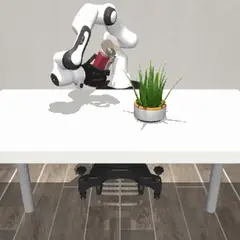
dexjoco-water-plantA trigger sprayer (a hand-held spray bottle with a trigger under its nozzle) stands on the table and a potted plant stands a little further away.…A trigger sprayer (a hand-held spray bottle with a trigger under its nozzle) stands on the table and a potted plant stands a little further away. Pick up the sprayer, bring its nozzle to the plant, and squeeze the trigger to water the plant.
Allegro hands on Franka arms2,500 stepsends when first reached
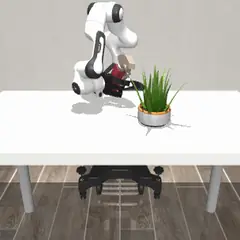
dexjoco-water-plant-bA trigger sprayer (a hand-held spray bottle with a trigger under its nozzle) stands on the table and a potted plant stands a little further away.…A trigger sprayer (a hand-held spray bottle with a trigger under its nozzle) stands on the table and a potted plant stands a little further away. Pick up the sprayer, bring its nozzle to the plant, and squeeze the trigger to water the plant.
Allegro hands on Franka arms2,500 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a folder in the task format, in tasks/dexjoco/ of Robo Use 0.6.1. The task text is shown here; the reference solution and the verifier are on GitHub.