Suites
A suite is a folder of tasks in the package: a subfolder of robouse tasks --path. Run one with robouse run-many --tasks "$(robouse tasks --path)/SUITE".
metaworld
gymrobotics
libero
robosuite
libero-style
arc-style
robo-use-families
safety
vision (a camera image the agent gets)
hard
menagerie
roboharm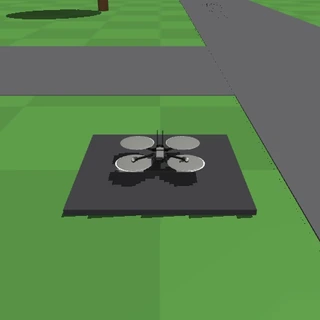
drone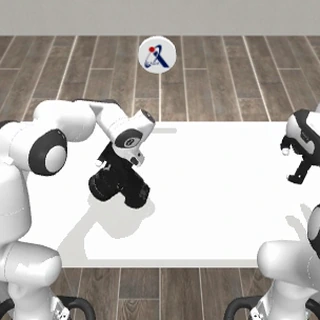
dexjoco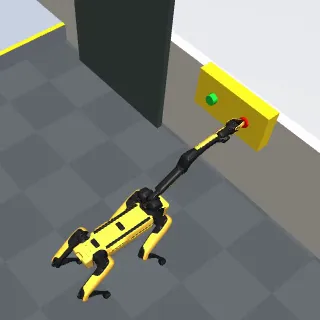
quadruped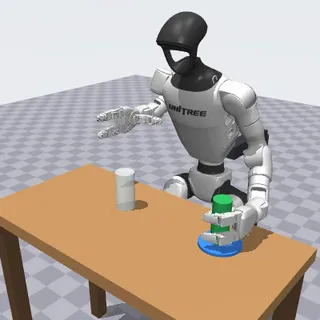
humanoid
mobile-manip
dexhand
crazyflie
driving
libero-90
kitchen
adroit
dmcontrol
myosuite
humanoidbench
maniskill
robocasarobouse 0.4.0 bundles 692 tasks in 31 suites. "Needs" is what a suite needs beyond pip install 'robouse[sim]', if anything. The last two columns count the tasks that scored 1 with the reference solution and with the no-op control.
| Suite | Tasks | Needs | Reference solution | No-op control |
|---|---|---|---|---|
adroitAdroit hand | 12 | [gymrobotics] | 12/12 | 0/12 |
arc-styleARC-style rules on a table | 11 | 11/11 | 0/11 | |
composedComposed from components | 48 | robouse fetch-assets --all | 48/48 | 0/48 |
crazyflieCrazyflie 2, one or three | 7 | robouse fetch-assets --all | 7/7 | 0/7 |
cubepickCube pick-and-reach | 5 | 5/5 | 0/5 | |
dexhandShadow Hand, LEAP Hand | 7 | robouse fetch-assets --all | 7/7 | 0/7 |
dexjocoDexJoCo: Allegro hand tool use | 14 | own virtualenv (below) | 14/14 | 0/14 |
dmcontroldm_control: Control Suite, Jaco arm | 17 | own virtualenv (below) | 17/17 | 0/17 |
drivingMetaDrive car in traffic | 7 | own virtualenv (below) | 7/7 | 0/7 |
droneSkydio X2 over a town | 10 | robouse fetch-assets | 10/10 | 0/10 |
gymroboticsGymnasium-Robotics: Fetch, PointMaze | 12 | [gymrobotics] | 12/12 | 0/12 |
hardLow-level control, uncalibrated cameras | 25 | 25/25 | 0/25 | |
humanoidUnitree G1 and H1, Apollo, Booster T1 | 9 | robouse fetch-assets --all | 9/9 | 0/9 |
humanoidbenchHumanoidBench: H1 with two hands | 7 | the hub only | 7/7 | 0/7 |
kitchenFranka Kitchen | 10 | [gymrobotics] | 10/10 | 0/10 |
liberoLIBERO: Spatial, Object, Goal, Long | 40 | LIBERO setup | 40/40 | 0/40 |
libero-90LIBERO-90 | 90 | LIBERO setup | 90/90 | 0/90 |
libero-styleLIBERO-like tabletop scenes | 12 | 12/12 | 0/12 | |
maniskillManiSkill3 on the CPU | 12 | the hub only | 12/12 | 0/12 |
menagerieDual Franka Panda, ALOHA 2 | 15 | robouse fetch-assets | 15/15 | 0/15 |
metaworldMeta-World MT50 | 50 | [metaworld] | 50/50 | 0/50 |
mobile-manipStretch 3, TIAGo, Google Robot | 10 | robouse fetch-assets --all | 10/10 | 0/10 |
myosuiteMyoSuite: muscle-driven arm and hand | 15 | own virtualenv (below) | 15/15 | 0/15 |
navObject-goal navigation in homes | 40 | 40/40 | 0/40 | |
quadrupedUnitree Go2 and Go1, Spot, ANYmal C | 11 | robouse fetch-assets --all | 11/11 | 0/11 |
robo-use-familiesRobo Use task families | 8 | 8/8 | 0/8 | |
robocasaRoboCasa kitchens | 24 | the hub only | 24/24 | 0/24 |
roboharm10 harm scenarios, 4 configurations | 80 | robouse fetch-assets | 80/80 | 0/80 |
robosuiterobosuite 1.5, five arms | 21 | [robosuite] | 21/21 | 0/21 |
safetyHarmful requests and benign twins | 8 | 8/8 | 0/8 | |
visionCamera images, no coordinates | 55 | [metaworld] | 55/55 | 0/55 |
robouse fetch-assets downloads the MuJoCo Menagerie robot models for menagerie, roboharm and drone; robouse fetch-assets --all adds every robot the other suites and composed tasks use (about 390 MB). Each file is checked by SHA-256. Results of models on these suites: Runs.
LIBERO pins robosuite 1.4, so it needs a virtual environment of its own:
python3.12 -m venv .venv-libero && source .venv-libero/bin/activate
pip install 'robouse[sim]' 'mujoco==3.3.0'
pip install --no-deps hf-libero==0.1.4 robosuite==1.4.0 bddl==1.0.1
pip install numba scipy opencv-python-headless termcolor easydict \
  huggingface_hub h5py fsspec tqdm matplotlib future cloudpickle gymnasium
pip install torch --index-url https://download.pytorch.org/whl/cpu
robouse run \
  --task libero-object-0 \
  --harness oracle \
  --out runs/try
The first episode downloads LIBERO's scene assets (about 400 MB) into ~/.cache/libero/assets. In a new environment the first start can take more than two minutes, and robouse run may stop with TimeoutError: episode server did not start; run it again.
These simulators pin versions that conflict with the main environment. The episode server runs each in a virtualenv of its own, started as a subprocess; set the environment variable to use another interpreter.
# dexjoco (ROBOUSE_DEXJOCO_PYTHON); also pip install 'robouse[dexjoco]'
git clone --depth 1 https://github.com/brave-eai/dexjoco.git \
  ~/.cache/robouse/dexjoco
uv venv -p 3.11 ~/.cache/robouse/dexjoco-venv
VIRTUAL_ENV=~/.cache/robouse/dexjoco-venv uv pip install \
  -e ~/.cache/robouse/dexjoco/dexjoco \
  "numcodecs<0.16"

# driving (ROBOUSE_METADRIVE_PYTHON)
uv venv -p 3.11 ~/.cache/robouse/metadrive-venv
uv pip install \
  -p ~/.cache/robouse/metadrive-venv/bin/python \
  metadrive-simulator==0.4.3

# dmcontrol (ROBOUSE_DMCONTROL_PYTHON)
uv venv -p 3.12 ~/.cache/robouse/dmcontrol-venv
uv pip install \
  -p ~/.cache/robouse/dmcontrol-venv/bin/python \
  dm-control==1.0.47

# myosuite (ROBOUSE_MYOSUITE_PYTHON)
uv venv -p 3.11 ~/.cache/robouse/myosuite-venv
uv pip install \
  -p ~/.cache/robouse/myosuite-venv/bin/python \
myosuite==2.12.2 scipy==1.16.2humanoidbench, maniskill and robocasa run from the hub, with bench eval run -d.
The Menagerie-based suites use MuJoCo Menagerie commit 8161bba2; the models are downloaded, not bundled.
| Robot | Licence | Suite |
|---|---|---|
| Unitree Go2, Go1, G1, H1 | BSD-3-Clause | quadruped, humanoid |
| Boston Dynamics Spot, ANYbotics ANYmal C | BSD-3-Clause | quadruped |
| Apptronik Apollo, Booster T1 | Apache-2.0 | humanoid |
| Hello Robot Stretch 3, PAL TIAGo, Google Robot | Apache-2.0 | mobile-manip |
| Shadow Hand E3M5 | Apache-2.0 | dexhand |
| LEAP Hand, Bitcraze Crazyflie 2 | MIT | dexhand, crazyflie |
The driving suite uses MetaDrive 0.4.3 (Apache-2.0).
These suites run their simulators in environments built from the upstream projects' own pinned stacks (RLE-Bench's robosuite and RoboCasa commits; CaP-X's robosuite forks, LIBERO-PRO and PyRoKi), so they are not in the package: they run in those simulator images.
| Suite | Tasks | Reference solution | No-op control |
|---|---|---|---|
rle-benchRLE-Bench family 03, tabletop reasoning: tower, cantilever, balance, hidden centre of mass | 6 | 6/6 | 0/6 |
capxCaP-X's robosuite tasks, code as policy with CaP-X's privileged API (simulator object poses, no perception) | 35 | 35/35 | 0/35 |
capx-liberoCaP-X on LIBERO-PRO's object-swap tasks, code as policy with CaP-X's privileged LIBERO API | 8 | 8/8 | 0/8 |