carlosferrazza/humanoid-bench
Whole-body tasks for a Unitree H1 with two Shadow hands.
ROBOUSE_ORACLE_TOKEN=$(openssl rand -hex 16) \
  bench eval run \
    -d carlosferrazza/humanoid-bench@0.2 \
    --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Unitree H1 humanoid with two Shadow hands
- Simulator
- HumanoidBench (MuJoCo 3.1.6)
- Requirements
- CPU only · 2 GB memory ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from HumanoidBench by Carmelo Sferrazza (UC Berkeley), MIT
- Versions
0.2current0.1Deprecated: superseded by 0.2
@misc{robouse_carlosferrazza_humanoid_bench_0_2,
  title        = {Robo Use carlosferrazza/humanoid-bench 0.2},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/carlosferrazza/humanoid-bench/}},
  note         = {BenchFlow dataset, tag carlosferrazza/humanoid-bench-v0.2, commit e472b1a1e041; adapted from HumanoidBench (Carmelo Sferrazza (UC Berkeley))}
}6 tasks
Task type
Size
Step budget
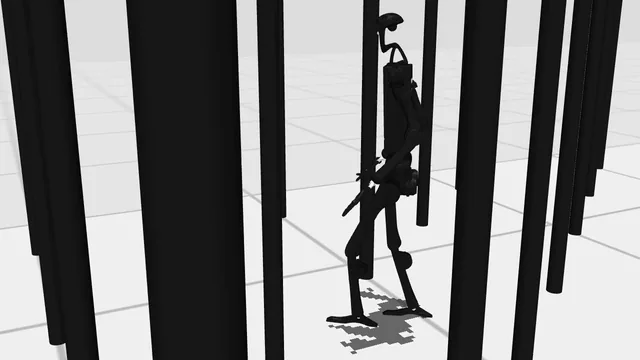
humanoidbench-poleWalk forward (+x) through a forest of thin vertical poles without touching them. The poles (radius 5 cm, 2 m tall, positions under scene.poles)…Walk forward (+x) through a forest of thin vertical poles without touching them. The poles (radius 5 cm, 2 m tall, positions under scene.poles) stand in rows 1 m apart from x = 1 m, 1.5 m apart within a row, alternate rows offset by 0.75 m; the corridor is closed by walls at y = +-3 m (their inner faces) and behind the start at x = -0.45 m. Each step's reward is 0.5 x (standing: head at least 1.65 m high, upright, small control) + 0.5 x (moving: the centre of mass's world-x velocity, 1 at 1 m/s or faster, falling linearly to 1/6 at 0 m/s), multiplied by 0.1 while any part of the robot touches a pole.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
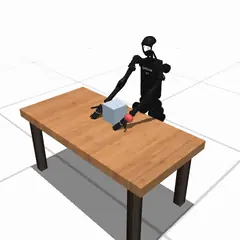
humanoidbench-pushMove the box on the table to the goal point scene.goal (the red marker in the camera view). The table top spans x 0.4-1.4 m, y -1-1 m, at 0.95 m…Move the box on the table to the goal point scene.goal (the red marker in the camera view). The table top spans x 0.4-1.4 m, y -1-1 m, at 0.95 m height; the box is a 0.2 m cube (0.3 kg) starting near (0.70, 0.0), resting on the table with its centre at z = 1.0, and the goal is on the table surface at the same height (scene.box_to_goal_m is the distance). The robot starts 0.4 m from the table edge, too far to reach the box; its legs meet the table when the pelvis is about 0.1 m from the edge (x = 0.3). The box may be pushed, slid or held between the hands; the Shadow hands' fingers stay straight and can snag the box's edges.
Unitree H1 humanoid with two Shadow hands500 stepsends when first reached
humanoidbench-reachPut the left hand on the target point scene.target and keep it there (scene.left_hand_to_target_m is the distance from the left hand to it).…Put the left hand on the target point scene.target and keep it there (scene.left_hand_to_target_m is the distance from the left hand to it). HumanoidBench's reach reward per step is 5 x torso uprightness (5 when upright) + 5 while the left hand is within 1 m of the target + 10 while it is within 5 cm of it, minus a tiny penalty on joint speeds: at most about 20 per step. Only the left hand counts.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
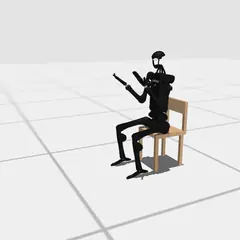
humanoidbench-sit-simpleSit down on the chair behind you and stay seated, upright and still. The chair (scene.chair: its position is the centre of its footprint on the…Sit down on the chair behind you and stay seated, upright and still. The chair (scene.chair: its position is the centre of its footprint on the floor) has a 0.42 x 0.42 m seat 0.475 m high and a backrest on its -x side; its seat centre is 0.25 m behind the robot's start position. HumanoidBench's sit reward is the product of: small control, not moving, upright (torso within about 18 degrees of vertical), a seated posture (head 0.35-0.45 m above the torso's IMU, which holds whenever the torso is upright) and 0.5 x sitting (pelvis 0.68-0.72 m above the floor) + 0.5 x on the chair (pelvis x within 0.19 m of the chair's x, and pelvis y at the chair's y: the term falls to 0.1 at 0.1 m sideways).
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
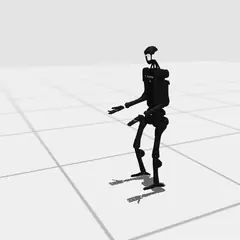
humanoidbench-standStand upright and still. HumanoidBench's stand reward is the product of: standing (head at least 1.65 m above the floor), upright (torso…Stand upright and still. HumanoidBench's stand reward is the product of: standing (head at least 1.65 m above the floor), upright (torso vertical), small control (small joint forces) and not moving (centre-of-mass speed near zero).
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
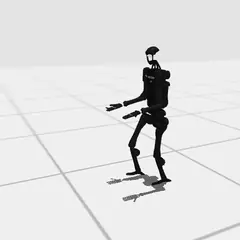
humanoidbench-walkWalk forward along +x at 1 m/s or faster while staying upright. HumanoidBench's walk reward is the product of: standing (head at least 1.65 m…Walk forward along +x at 1 m/s or faster while staying upright. HumanoidBench's walk reward is the product of: standing (head at least 1.65 m above the floor), upright, small control, and moving (the centre of mass's world-x velocity: 1 when it is at least 1 m/s, falling linearly to 1/6 at 0 m/s). Only the velocity along the world x axis counts, so keep the heading near 0.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit e472b1a1e041. The verifier and the reference solution are not published.