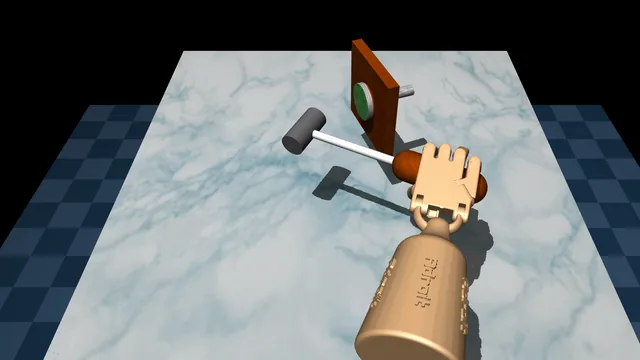
farama-foundation/adroit-hand
Door, hammer, pen and relocation tasks with the ADROIT hand.
robouse run-many \
  --tasks "$(robouse tasks --path)/adroit" \
  --harness claude-code \
--out runs/adroitAbout this dataset
- Embodiment
- ADROIT hand
- Simulator
- Gymnasium-Robotics 1.4.2 (Adroit hand)
- Needs
pip install 'robouse[sim]', thenpip install 'robouse[gymrobotics]'- Release
- Robo Use 0.6.1, suite
adroit - Licence
- Task text and reference solutions Apache-2.0 (Robo Use); adapted from Adroit hand (Gymnasium-Robotics; DAPG) by Farama Foundation, MIT (code); Apache-2.0 (ADROIT assets); CC BY 4.0 (D4RL demonstrations; action sequences redistributed here)
12 tasks
Budget
Budget
adroit-door-e11Unlatch the door and swing it open.
ADROIT hand1,000 stepsjudged on the final state
adroit-door-e18Unlatch the door and swing it open.
ADROIT hand1,000 stepsjudged on the final state
adroit-door-e23Unlatch the door and swing it open.
ADROIT hand1,000 stepsjudged on the final state
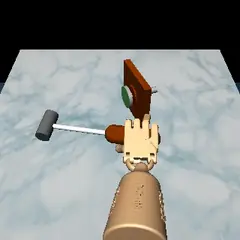
adroit-hammer-e14Pick up the hammer and drive the nail into the board.
ADROIT hand1,500 stepsjudged on the final state
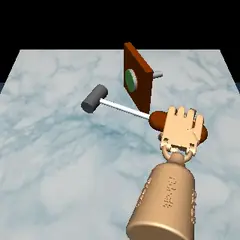
adroit-hammer-e18Pick up the hammer and drive the nail into the board.
ADROIT hand1,500 stepsjudged on the final state
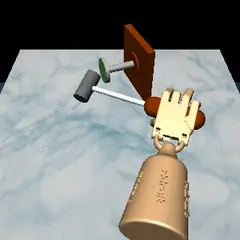
adroit-hammer-e19Pick up the hammer and drive the nail into the board.
ADROIT hand1,500 stepsjudged on the final state
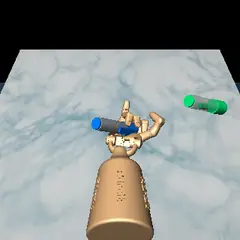
Rotate the pen in the hand to match the target orientation.
ADROIT hand600 stepsjudged on the final state
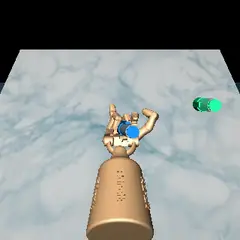
Rotate the pen in the hand to match the target orientation.
ADROIT hand600 stepsjudged on the final state
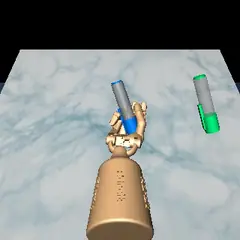
Rotate the pen in the hand to match the target orientation.
ADROIT hand600 stepsjudged on the final state
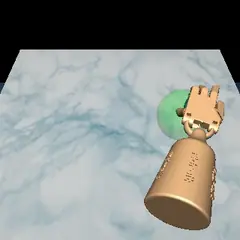
adroit-relocate-e0Pick up the ball and move it to the target position.
ADROIT hand1,500 stepsjudged on the final state
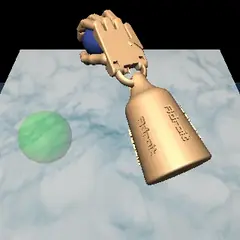
adroit-relocate-e17Pick up the ball and move it to the target position.
ADROIT hand1,500 stepsjudged on the final state
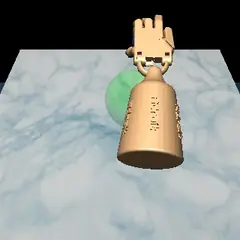
adroit-relocate-e5Pick up the ball and move it to the target position.
ADROIT hand1,500 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a folder in the task format, in tasks/adroit/ of Robo Use 0.6.1. The task text is shown here; the reference solution and the verifier are on GitHub.