haosulab/maniskill-gpu
Hard ManiSkill3 tasks with ray-traced cameras, on a Franka Panda.
robouse run-many \
  --tasks tasks/gpu-maniskill \
  --harness oracle \
--out runs/gpu-maniskill-oracleAbout this dataset
- Embodiment
- Franka Panda
- Simulator
- ManiSkill3 3.0.1 (SAPIEN, ray-traced)
- Requirements
- NVIDIA RTX GPU ·
bench>=0.7.4,<0.8 · runs from a Robo Use checkout - Licence
- Task packages Apache-2.0; adapted from ManiSkill3 by Hao Su Lab (UC San Diego) and Hillbot, Apache-2.0
@misc{robouse_haosulab_maniskill_gpu_0_1,
  title        = {Robo Use haosulab/maniskill-gpu 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/haosulab/maniskill-gpu/}},
  note         = {BenchFlow dataset, tag haosulab/maniskill-gpu-v0.1, commit 9ad3e1a903c6; adapted from ManiSkill3 (Hao Su Lab (UC San Diego) and Hillbot)}
}12 tasks
Size
Step budget
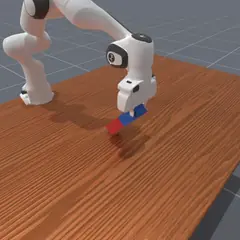
ms-lift-peg-uprightA peg lies on its side on the table. Stand it upright on one of its end faces, so that its long axis is vertical, resting on the table. The task…A peg lies on its side on the table. Stand it upright on one of its end faces, so that its long axis is vertical, resting on the table. The task is solved when the peg's long axis is within about 5 degrees (0.08 rad) of vertical and its centre is within 5 mm of half its length above the table.
Franka Panda40 stepsjudged on the final state
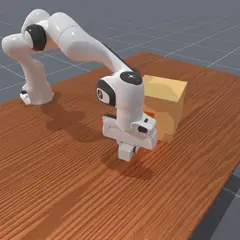
ms-peg-insertion-moving-boxPick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail…Pick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail half white. Insert the orange head first: the task is solved when the peg's head end is inside the hole and at least half-way through the box's depth (the head end within 15 mm of the box centre along the hole or past it), and inside the hole's cross-section.
Franka Panda50 stepsjudged on the final state
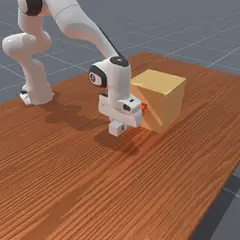
ms-peg-insertion-sidePick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail…Pick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail half white. Insert the orange head first: the task is solved when the peg's head end is inside the hole and at least half-way through the box's depth (the head end within 15 mm of the box centre along the hole or past it), and inside the hole's cross-section.
Franka Panda40 stepsjudged on the final state
ms-peg-insertion-side-1mmPick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail…Pick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail half white. Insert the orange head first: the task is solved when the peg's head end is inside the hole and at least half-way through the box's depth (the head end within 15 mm of the box centre along the hole or past it), and inside the hole's cross-section.
Franka Panda40 stepsjudged on the final state
ms-peg-insertion-side-visionPick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail…Pick up the peg lying on the table and insert it into the hole in the side of the box. The peg is a square bar: its head half is orange, its tail half white. Insert the orange head first: the task is solved when the peg's head end is inside the hole and at least half-way through the box's depth (the head end within 15 mm of the box centre along the hole or past it), and inside the hole's cross-section.
Franka Panda60 stepsjudged on the final state
ms-pick-moving-cubeA 4 cm red cube slides across the table at a constant 5 cm/s, as if on a conveyor belt: it moves 2.5 mm every control step (0.05 s of simulated…A 4 cm red cube slides across the table at a constant 5 cm/s, as if on a conveyor belt: it moves 2.5 mm every control step (0.05 s of simulated time), in a straight line along the y axis, until it is grasped or lifted. When it passes y = 0.3 m (or -0.3 m) it is carried off the end of the belt, out of reach, and the task can no longer be solved. Simulated time only passes when the robot acts: each robo act step is 0.05 s, and a robo skill takes as long as its motion does (a move typically 0.5-2 s). Grasp the cube and bring it to the goal point, holding it there with the arm still. The task is solved when the cube's centre is within 2.5 cm of the goal point and the robot is static.
Franka Panda150 stepsjudged on the final state
ms-pick-moving-cube-visionA 4 cm red cube slides across the table at a constant 5 cm/s, as if on a conveyor belt: it moves 2.5 mm every control step (0.05 s of simulated…A 4 cm red cube slides across the table at a constant 5 cm/s, as if on a conveyor belt: it moves 2.5 mm every control step (0.05 s of simulated time), in a straight line along the y axis, until it is grasped or lifted. When it passes y = 0.3 m (or -0.3 m) it is carried off the end of the belt, out of reach, and the task can no longer be solved. Simulated time only passes when the robot acts: each robo act step is 0.05 s, and a robo skill takes as long as its motion does. Grasp the cube and bring it to the goal point (goal_pos in robo observe, in the air above the table), holding it there with the arm still. The task is solved when the cube's centre is within 2.5 cm of the goal point and the robot is static.
Franka Panda150 stepsjudged on the final state
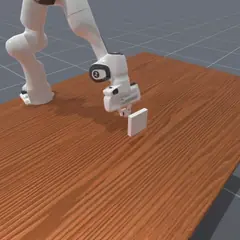
ms-plug-chargerPick up the charger (a small block with two metal prongs) and plug it into the receptacle on the wall: both prongs must go into the receptacle's…Pick up the charger (a small block with two metal prongs) and plug it into the receptacle on the wall: both prongs must go into the receptacle's two holes. The holes leave 0.5 mm of clearance around each prong. The task is solved when the charger is within 5 mm and 0.2 rad of the fully inserted pose.
Franka Panda40 stepsjudged on the final state
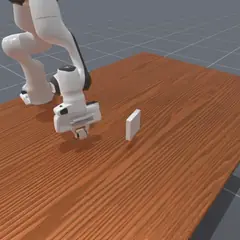
ms-plug-charger-visionPick up the charger (a small block with two metal prongs) and plug it into the receptacle on the wall: both prongs must go into the receptacle's…Pick up the charger (a small block with two metal prongs) and plug it into the receptacle on the wall: both prongs must go into the receptacle's two holes, which leave 0.5 mm of clearance around each prong. The task is solved when the charger is within 5 mm and 0.2 rad of the fully inserted pose.
Franka Panda60 stepsjudged on the final state
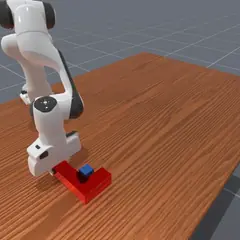
ms-pull-cube-toolThe red cube is out of the arm's reach. Use the L-shaped tool on the table: grasp its handle, place its hook behind the cube (on the far side…The red cube is out of the arm's reach. Use the L-shaped tool on the table: grasp its handle, place its hook behind the cube (on the far side from the robot), and pull the cube towards the robot base. The task is solved when the cube's centre is within 0.6 m (measured horizontally) of the robot base at (-0.615, 0).
Franka Panda40 stepsjudged on the final state
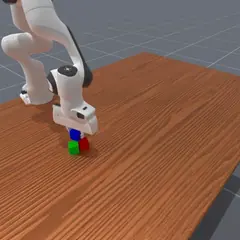
ms-stack-pyramidBuild a pyramid from the three 4 cm cubes: put the red cube (cubeA) directly beside the green cube (cubeB) so that the two touch, then set the…Build a pyramid from the three 4 cm cubes: put the red cube (cubeA) directly beside the green cube (cubeB) so that the two touch, then set the blue cube (cubeC) on top of both, resting on the two of them. The task is solved when A and B are side by side on the table, C rests on both, and nothing is moving.
Franka Panda40 stepsjudged on the final state
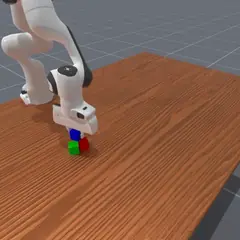
ms-stack-pyramid-visionBuild a pyramid from the three 4 cm cubes: put the red cube directly beside the green cube so that the two touch, then set the blue cube on top…Build a pyramid from the three 4 cm cubes: put the red cube directly beside the green cube so that the two touch, then set the blue cube on top of both, resting on the two of them. The task is solved when red and green are side by side on the table, blue rests on both, and nothing is moving.
Franka Panda60 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9ad3e1a903c6. The verifier and the reference solution are not published.