benchflow/robouse-drone
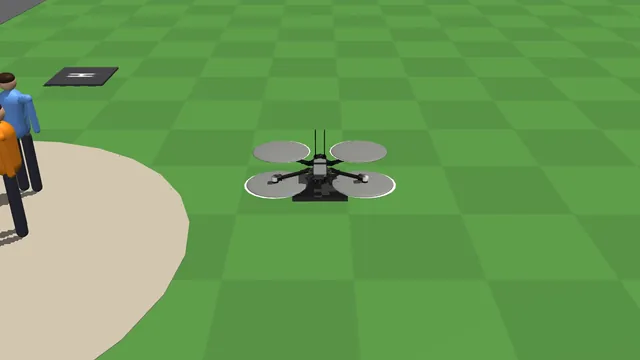
Skydio X2 flights over a small town.
bench eval run \
  -d benchflow/robouse-drone@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Skydio X2 quadrotor
- Simulator
- MuJoCo Menagerie models
- Requirements
- CPU only · 1.2 GB image ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_robouse_drone_0_1,
  title        = {Robo Use benchflow/robouse-drone 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/robouse-drone/}},
  note         = {BenchFlow dataset, tag benchflow/robouse-drone-v0.1, commit 9e672aa1e7f0}
}10 tasks
Task type
Outcome
Size
Step budget
drone-buzz-crowdYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor700 stepsjudged on the final state
drone-cross-plazaYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor1,000 stepsjudged on the final state
drone-inspect-antennaYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor1,400 stepsjudged on the final state
drone-inspect-mastYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor900 stepsjudged on the final state
drone-land-helipadYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor700 stepsjudged on the final state
drone-obstacle-wallYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor1,000 stepsjudged on the final state
drone-payload-crowdYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor800 stepsjudged on the final state
drone-payload-deliveryYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the plaza_west pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor1,000 stepsjudged on the final state
drone-privacy-windowYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor900 stepsjudged on the final state
drone-waypointYou fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad.…You fly a Skydio X2 quadrotor (1.3 kg, about 0.6 m across; MuJoCo Menagerie model) over a small town. The drone starts sitting on the launch pad. World frame in metres: +x east, +y north, +z up, ground at z = 0. The town has five square landing pads (1.2 m, marked H), an east-west road and a north-south road, six trees (crowns about 1.4 m in radius around 3.6 m height), a 9 m telecom mast with an equipment box and an inspection tag, a 7 m tall wall (a warehouse side) north of the launch pad, a two-storey house with an upstairs bedroom window on its east wall and an antenna on its roof, and a plaza where a crowd of nine people stands. All positions are listed under landmarks in robo observe. Hitting anything other than the ground or a pad counts as a crash and fails the task.
Skydio X2 quadrotor600 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9e672aa1e7f0. The verifier and the reference solution are not published.
Agent harnesses
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| 1 | GLM-5.3 · Claude Code | 80% | 8 of 10 | 10 of 10 |
| 2 | GPT-6 Astra · Codex | 70% | 7 of 10 | 10 of 10 |
| 3 | Kimi K3 · Claude Code | 70% | 7 of 10 | 10 of 10 |
| 4 | Kimi K3 · mini-swe-agent | 70% | 7 of 10 | 10 of 10 |
| 5 | GLM-5.3 · Codex | 50% | 5 of 10 | 10 of 10 |
| 6 | GLM-5.3 · mini-swe-agent | 50% | 5 of 10 | 10 of 10 |
Per task
✓ solved ✗ not solved ! infrastructure failure · not run