benchflow/robouse-playground
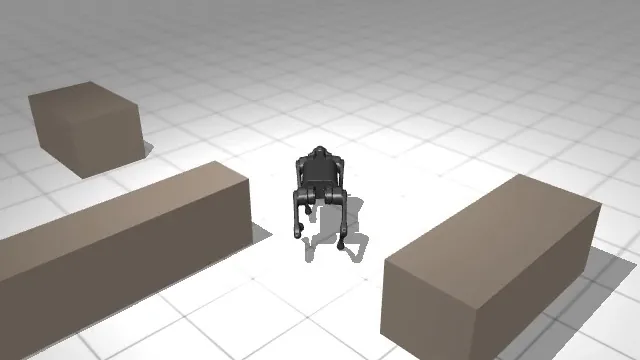
A Unitree Go1 with a learned gait navigating obstacles.
robouse run-many \
  --tasks tasks/gpu-playground \
  --harness oracle \
--out runs/gpu-playground-oracleAbout this dataset
- Embodiment
- Unitree Go1 with a learned gait
- Simulator
- MuJoCo Playground 0.2.0 (MuJoCo Warp)
- Requirements
- NVIDIA RTX GPU ·
bench>=0.7.4,<0.8 · runs from a Robo Use checkout - Licence
- Task packages Apache-2.0
@misc{robouse_benchflow_robouse_playground_0_1,
  title        = {Robo Use benchflow/robouse-playground 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/benchflow/robouse-playground/}},
  note         = {BenchFlow dataset, tag benchflow/robouse-playground-v0.1, commit 9ad3e1a903c6}
}5 tasks
Task type
Size
Step budget
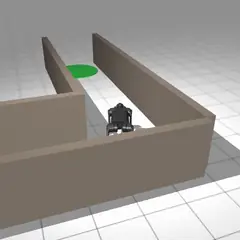
pg-go1-corridor-pushYou control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it through the corridor to the goal at its far end (within…You control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it through the corridor to the goal at its far end (within 0.4 m of goal) without touching the walls and without falling. The corridor is 0.9 m wide and has two 90-degree turns. Every few seconds a random shove pushes the robot (the policy keeps it on its feet, but it gets knocked off course).
Unitree Go1 with a learned gait100 stepsjudged on the final state
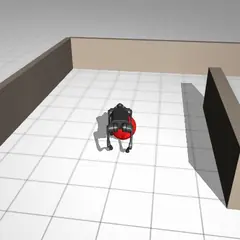
pg-go1-find-ballYou control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m) in an 8 x 8 m room (walls at x = +-4 and y = +-4) with four low…You control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m) in an 8 x 8 m room (walls at x = +-4 and y = +-4) with four low interior walls. A red ball (30 cm across) lies somewhere in the room, hidden behind one of the interior walls. Find it and stop with the robot's base within 0.6 m of the ball's centre, without touching any wall and without falling.
Unitree Go1 with a learned gait100 stepsjudged on the final state
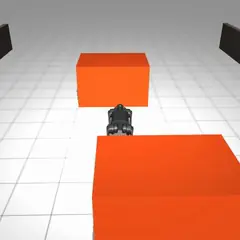
pg-go1-moving-gatesYou control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it from the start to the goal at the far end of the hall…You control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it from the start to the goal at the far end of the hall (within 0.4 m of goal). Three orange blocks slide back and forth across the hall along y (each moves along a fixed line x = x, up to 1.8 m to either side of the centre line, repeating every 8-12 s). The robot must not touch a block or the side walls, and must not fall.
Unitree Go1 with a learned gait200 stepsjudged on the final state
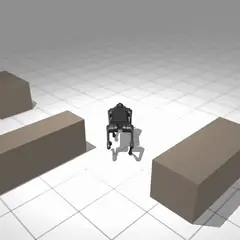
pg-go1-obstacle-fieldYou control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it to the goal: stop with its base inside the green disc…You control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Walk it to the goal: stop with its base inside the green disc (within 0.4 m of goal) without touching any obstacle and without falling.
Unitree Go1 with a learned gait80 stepsjudged on the final state
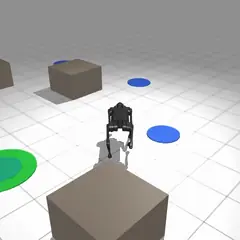
pg-go1-waypoint-tourYou control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Visit the six waypoints (blue discs) in the order listed in…You control a Unitree Go1 quadruped (about 0.6 m long; footprint radius 0.32 m). Visit the six waypoints (blue discs) in the order listed in waypoints: the robot's base must come within 0.35 m of each waypoint, in order, and the episode must end with the robot standing at the last one. Do not touch the pillars and do not fall. next_waypoint in robo observe counts the waypoints reached so far (a waypoint only counts when all earlier ones have been reached).
Unitree Go1 with a learned gait250 stepsjudged on the final state
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9ad3e1a903c6. The verifier and the reference solution are not published.