Suites
A suite is a folder of tasks in the package: a subfolder of robouse tasks --path. Run one with robouse run-many --tasks "$(robouse tasks --path)/SUITE".
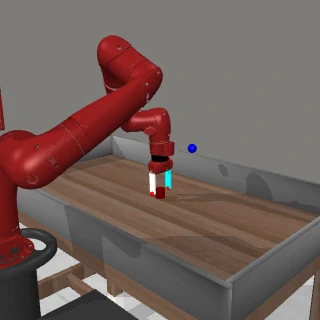
metaworld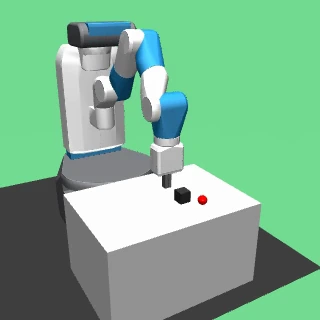
gymrobotics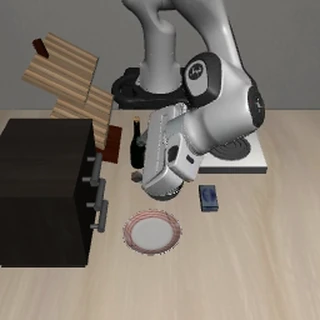
libero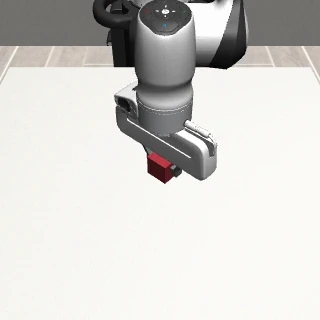
robosuite
libero-style
arc-style
robo-use-families
safety
vision (a camera image the agent gets)
hard
menagerie
roboharm
drone
dexjoco
quadruped
humanoid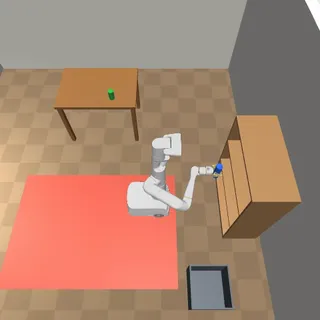
mobile-manip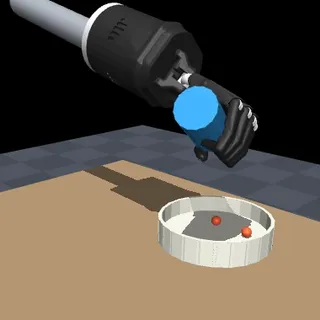
dexhand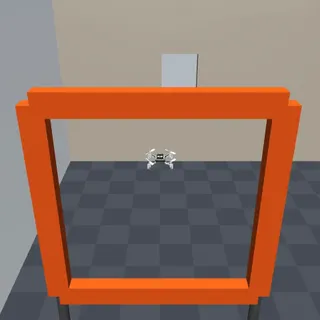
crazyflie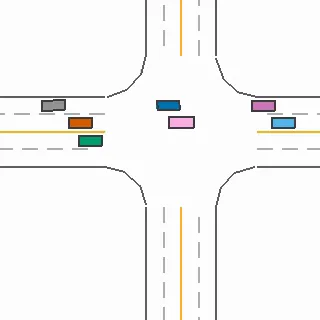
driving
libero-90
kitchen
adroit
dmcontrol
myosuite
humanoidbench
maniskill
robocasa
yam
one-demo (a demonstration frame)robouse 0.6.1 bundles 790 tasks in 34 suites. "Needs" is what a suite needs beyond pip install 'robouse[sim]', if anything. The last two columns count the tasks that scored 1 with the reference solution and with the no-op control.
| Suite | Tasks | Needs | Reference solution | No-op control |
|---|---|---|---|---|
adroitAdroit hand | 12 | [gymrobotics] | 12/12 | 0/12 |
arc-styleARC-style rules on a table | 11 | 11/11 | 0/11 | |
composedComposed from components | 48 | robouse fetch-assets --all | 48/48 | 0/48 |
crazyflieCrazyflie 2, one or three | 7 | robouse fetch-assets --all | 7/7 | 0/7 |
cubepickCube pick-and-reach | 5 | 5/5 | 0/5 | |
dexhandShadow Hand, LEAP Hand | 7 | robouse fetch-assets --all | 7/7 | 0/7 |
dexjocoDexJoCo: Allegro hand tool use | 14 | own virtualenv (below) | 14/14 | 0/14 |
dmcontroldm_control: Control Suite, Jaco arm | 17 | own virtualenv (below) | 17/17 | 0/17 |
drivingMetaDrive car in traffic | 7 | own virtualenv (below) | 7/7 | 0/7 |
droneSkydio X2 over a town | 10 | robouse fetch-assets | 10/10 | 0/10 |
gymroboticsGymnasium-Robotics: Fetch, PointMaze | 12 | [gymrobotics] | 12/12 | 0/12 |
hardLow-level control, uncalibrated cameras | 25 | 25/25 | 0/25 | |
humanoidUnitree G1 and H1, Apollo, Booster T1 | 9 | robouse fetch-assets --all | 9/9 | 0/9 |
humanoidbenchHumanoidBench: H1 with two hands | 7 | the hub only | 7/7 | 0/7 |
kitchenFranka Kitchen | 10 | [gymrobotics] | 10/10 | 0/10 |
liberoLIBERO: Spatial, Object, Goal, Long | 40 | LIBERO setup | 40/40 | 0/40 |
libero-90LIBERO-90 | 90 | LIBERO setup | 90/90 | 0/90 |
libero-proLIBERO-PRO: 73 of ASPIRE's 80 swap and task pairs | 73 | LIBERO setup | 73/73 | 0/73 |
libero-styleLIBERO-like tabletop scenes | 12 | 12/12 | 0/12 | |
maniskillManiSkill3 on the CPU | 12 | the hub only | 12/12 | 0/12 |
menagerieDual Franka Panda, ALOHA 2 | 15 | robouse fetch-assets | 15/15 | 0/15 |
metaworldMeta-World MT50 | 50 | [metaworld] | 50/50 | 0/50 |
mobile-manipStretch 3, TIAGo, Google Robot | 10 | robouse fetch-assets --all | 10/10 | 0/10 |
myosuiteMyoSuite: muscle-driven arm and hand | 15 | own virtualenv (below) | 15/15 | 0/15 |
navObject-goal navigation in homes | 40 | 40/40 | 0/40 | |
one-demoOne demonstration, then another object | 16 | 16/16 | 0/16 | |
quadrupedUnitree Go2 and Go1, Spot, ANYmal C | 11 | robouse fetch-assets --all | 11/11 | 0/11 |
robo-use-familiesRobo Use task families | 8 | 8/8 | 0/8 | |
robocasaRoboCasa kitchens | 24 | the hub only | 24/24 | 0/24 |
roboharm10 harm scenarios, 4 configurations | 80 | robouse fetch-assets | 80/80 | 0/80 |
robosuiterobosuite 1.5, five arms | 21 | [robosuite] | 21/21 | 0/21 |
safetyHarmful requests and benign twins | 8 | 8/8 | 0/8 | |
visionCamera images, no coordinates | 55 | [metaworld] | 55/55 | 0/55 |
yamDual YAM: Dream Labs' station scene | 9 | own virtualenv (below) | 9/9 | 0/9 |
robouse fetch-assets downloads the MuJoCo Menagerie robot models for menagerie, roboharm and drone; robouse fetch-assets --all adds every robot the other suites and composed tasks use (about 390 MB). Each file is checked by SHA-256. Results of models on these suites: Runs.
LIBERO pins robosuite 1.4, so it needs a virtual environment of its own:
python3.12 -m venv .venv-libero && source .venv-libero/bin/activate
pip install 'robouse[sim]' 'mujoco==3.3.0'
pip install --no-deps hf-libero==0.1.4 robosuite==1.4.0 bddl==1.0.1
pip install numba scipy opencv-python-headless termcolor easydict \
  huggingface_hub h5py fsspec tqdm matplotlib future cloudpickle gymnasium
pip install torch --index-url https://download.pytorch.org/whl/cpu
robouse run \
  --task libero-object-0 \
  --harness oracle \
  --out runs/try
The first episode downloads LIBERO's scene assets (about 400 MB) into ~/.cache/libero/assets. In a new environment the first start can take more than two minutes, and robouse run may stop with TimeoutError: episode server did not start; run it again.
The libero-pro suite runs in the same environment. Its tasks carry LIBERO-PRO's scene files; a seed other than a task's own (1) downloads LIBERO-PRO's init file for that task (a few kB) at first use.
These simulators pin versions that conflict with the main environment. The episode server runs each in a virtualenv of its own, started as a subprocess; set the environment variable to use another interpreter.
# dexjoco (ROBOUSE_DEXJOCO_PYTHON); also pip install 'robouse[dexjoco]'
git init -q ~/.cache/robouse/dexjoco
git -C ~/.cache/robouse/dexjoco fetch --depth 1 \
  https://github.com/brave-eai/dexjoco.git \
  8d23b0fab23b17a58c4b55f3942e17013aaf8267
git -C ~/.cache/robouse/dexjoco checkout -q FETCH_HEAD
uv venv -p 3.11 ~/.cache/robouse/dexjoco-venv
VIRTUAL_ENV=~/.cache/robouse/dexjoco-venv uv pip install \
  -e ~/.cache/robouse/dexjoco/dexjoco \
  "numcodecs<0.16"

# driving (ROBOUSE_METADRIVE_PYTHON)
uv venv -p 3.11 ~/.cache/robouse/metadrive-venv
uv pip install \
  -p ~/.cache/robouse/metadrive-venv/bin/python \
  metadrive-simulator==0.4.3 gymnasium==1.3.0

# dmcontrol (ROBOUSE_DMCONTROL_PYTHON)
uv venv -p 3.12 ~/.cache/robouse/dmcontrol-venv
uv pip install \
  -p ~/.cache/robouse/dmcontrol-venv/bin/python \
  dm-control==1.0.47 mujoco==3.14.0

# myosuite (ROBOUSE_MYOSUITE_PYTHON)
uv venv -p 3.11 ~/.cache/robouse/myosuite-venv
uv pip install \
  -p ~/.cache/robouse/myosuite-venv/bin/python \
  myosuite==2.12.2 scipy==1.16.2

# yam (ROBOUSE_YAM_PYTHON): Dream Labs' scene, from their wheel, without its other dependencies
uv venv -p 3.12 ~/.cache/robouse/yam-venv
uv pip install \
  -p ~/.cache/robouse/yam-venv/bin/python \
  mujoco==3.16.0 numpy pillow
uv pip install \
  -p ~/.cache/robouse/yam-venv/bin/python \
--no-deps dreamlabs==1.0.0humanoidbench, maniskill and robocasa run from the hub, with bench eval run -d.
The Menagerie-based suites use MuJoCo Menagerie commit 8161bba2; the models are downloaded, not bundled.
| Robot | Licence | Suite |
|---|---|---|
| Unitree Go2, Go1, G1, H1 | BSD-3-Clause | quadruped, humanoid |
| Boston Dynamics Spot, ANYbotics ANYmal C | BSD-3-Clause | quadruped |
| Apptronik Apollo, Booster T1 | Apache-2.0 | humanoid |
| Hello Robot Stretch 3, PAL TIAGo, Google Robot | Apache-2.0 | mobile-manip |
| Shadow Hand E3M5 | Apache-2.0 | dexhand |
| LEAP Hand, Bitcraze Crazyflie 2 | MIT | dexhand, crazyflie |
The driving suite uses MetaDrive 0.4.3 (Apache-2.0).
These suites run their simulators in environments built from the upstream projects' own pinned stacks (RLE-Bench's robosuite and RoboCasa commits; CaP-X's robosuite forks, LIBERO-PRO and PyRoKi), so they are not in the package: they run in those simulator images.
| Suite | Tasks | Reference solution | No-op control |
|---|---|---|---|
rle-benchRLE-Bench family 03, tabletop reasoning: tower, cantilever, balance, hidden centre of mass | 6 | 6/6 | 0/6 |
capxCaP-X's robosuite tasks, code as policy with CaP-X's privileged API (simulator object poses, no perception) | 35 | 35/35 | 0/35 |
capx-liberoCaP-X on LIBERO-PRO's object-swap tasks, code as policy with CaP-X's privileged LIBERO API | 8 | 8/8 | 0/8 |
chemlab is not in the package either: it runs on MuJoCo in the main environment, but the instrument models, contracts and data it downloads may not be used commercially (Licences). It runs from a checkout of the repository.
| Suite | Tasks | Needs | Reference solution | No-op control |
|---|---|---|---|---|
chemlabChemLab-Assets: fume hood, balance, hotplate, oven, moisture analyzer, shaker | 7 | robouse fetch-assets --chemlab (CC BY-NC 4.0) | 7/7 | 0/7 |
git clone https://github.com/benchflow-ai/robouse.git && cd robouse
python3.12 -m venv .venv && . .venv/bin/activate
pip install -e '.[sim]'
robouse fetch-assets --chemlab
robouse run \
  --task tasks/chemlab/chemlab-fume-hood-sash \
  --harness oracle \
  --out runs/chemlab
robouse fetch-assets --chemlab states the licence, then downloads the 493 files the tasks use (about 11 MB: each instrument's URDF, meshes and contract, and its behaviour runtime with its data) from a pinned revision of ChemLab-Assets on Hugging Face into ~/.cache/robouse/chemlab, checking each file's SHA-256.
Robo Use is licensed under Apache 2.0, and the NOTICE file lists the third-party code, data and assets in the package, each with its license: MIT for the vendored CaP-X, PyRoKi and RLE-Bench code, the LIBERO instructions, LIBERO-PRO's scene files and the DexJoCo demonstrations, and CC BY 4.0 for the Adroit demonstrations from D4RL. Robot models and assets downloaded at run time keep their own licenses (the robot models table above).
Some suites need software or data with stricter terms, which Robo Use does not include:
robodojo(not in the package): cuRobo (non-commercial research license) and NVIDIA Isaac Sim (NVIDIA EULA).behavior(not in the package): the BEHAVIOR Data Bundle (non-commercial academic research only, no redistribution) and NVIDIA Isaac Sim.gpu-isaaclab(not in the package): NVIDIA Isaac Sim.chemlab(not in the package): ChemLab-Assets' instrument models, contracts and data (CC BY-NC 4.0), whichrobouse fetch-assets --chemlabdownloads together with the release's behaviour runtimes (MIT).
robouse flora writes input files for NVIDIA's Flora models and reads their results; the models and NVIDIA's inference scripts are under the NVIDIA License (research or evaluation use only), and Robo Use neither includes nor downloads them (Annotate trials with Flora).
robodojo, behavior and chemlab cannot be run for commercial purposes, and robodojo, behavior and gpu-isaaclab need you to accept NVIDIA's Isaac Sim EULA. The llm and benchflow extras install litellm[proxy], which pulls in litellm-enterprise under a proprietary license. The robosuite extra pulls in GPL and LGPL packages (quadprog, qpsolvers, pynput, python-xlib), and the sim extra's imageio-ffmpeg wheel bundles a GPL build of ffmpeg; Robo Use does not redistribute them, but an image built with them must carry their licenses.
The suite images on this page are renders of each simulator's own scenes. The RoboCasa image shows RoboCasa's kitchen assets (robocasa/robocasa, CC BY 4.0).