carlosferrazza/humanoid-bench
Whole-body tasks for a Unitree H1 with two Shadow hands.
bench eval run \
  -d carlosferrazza/humanoid-bench@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Unitree H1 humanoid with two Shadow hands
- Simulator
- HumanoidBench (MuJoCo 3.1.6)
- Requirements
- CPU only · 2 GB memory ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from HumanoidBench by Carmelo Sferrazza (UC Berkeley), MIT
@misc{robouse_carlosferrazza_humanoid_bench_0_1,
  title        = {Robo Use carlosferrazza/humanoid-bench 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/carlosferrazza/humanoid-bench/}},
  note         = {BenchFlow dataset, tag carlosferrazza/humanoid-bench-v0.1, commit bcd0d002b9df; adapted from HumanoidBench (Carmelo Sferrazza (UC Berkeley))}
}7 tasks
Task type
Size
Step budget
humanoidbench-mazeWalk through a maze of 1.5 m wall blocks (1.2 m high) along its corridor, through the checkpoints (3, 0), (3, 6) and (6, 6) in that order…Walk through a maze of 1.5 m wall blocks (1.2 m high) along its corridor, through the checkpoints (3, 0), (3, 6) and (6, 6) in that order (scene.checkpoints, scene.next_checkpoint; the wall blocks are listed under scene.walls as x and y ranges). A checkpoint counts when the pelvis comes within 0.4 m of it and gives a one-off bonus of 100 x the number of checkpoints reached so far (the start point (0, 0) counts as the first, so the four bonuses add up to 1000). Every step also rewards standing upright, moving toward the next checkpoint at 2 m/s and being close to it (after the last checkpoint, staying near it); touching a wall multiplies that step's reward by 0.1.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
humanoidbench-poleWalk forward (+x) through a forest of thin vertical poles without touching them. The poles (radius 5 cm, 2 m tall, positions under scene.poles)…Walk forward (+x) through a forest of thin vertical poles without touching them. The poles (radius 5 cm, 2 m tall, positions under scene.poles) stand in rows 1 m apart from x = 1 m, 1.5 m apart within a row, alternate rows offset by 0.75 m; the corridor is closed by walls at y = +-3 m (their inner faces) and behind the start at x = -0.45 m. Each step's reward is 0.5 x (standing: head at least 1.65 m high, upright, small control) + 0.5 x (moving: the centre of mass's world-x velocity, 1 at 1 m/s or faster, falling linearly to 1/6 at 0 m/s), multiplied by 0.1 while any part of the robot touches a pole.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
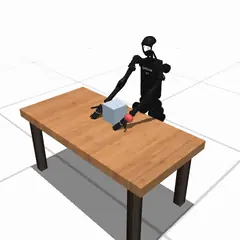
humanoidbench-pushMove the box on the table to the goal point scene.goal (the red marker in the camera view). The table top spans x 0.4-1.4 m, y -1-1 m, at 0.95 m…Move the box on the table to the goal point scene.goal (the red marker in the camera view). The table top spans x 0.4-1.4 m, y -1-1 m, at 0.95 m height; the box is a 0.2 m cube (0.3 kg) starting near (0.70, 0.0), resting on the table with its centre at z = 1.0, and the goal is on the table surface at the same height (scene.box_to_goal_m is the distance). The robot starts 0.4 m from the table edge, too far to reach the box; its legs meet the table when the pelvis is about 0.1 m from the edge (x = 0.3). The box may be pushed, slid or held between the hands; the Shadow hands' fingers stay straight and can snag the box's edges.
Unitree H1 humanoid with two Shadow hands500 stepsends when first reached
humanoidbench-reachPut the left hand on the target point scene.target and keep it there (scene.left_hand_to_target_m is the distance from the left hand to it).…Put the left hand on the target point scene.target and keep it there (scene.left_hand_to_target_m is the distance from the left hand to it). HumanoidBench's reach reward per step is 5 x torso uprightness (5 when upright) + 5 while the left hand is within 1 m of the target + 10 while it is within 5 cm of it, minus a tiny penalty on joint speeds: at most about 20 per step. Only the left hand counts.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
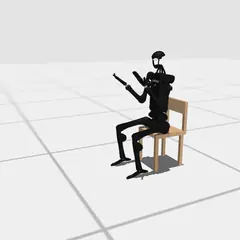
humanoidbench-sit-simpleSit down on the chair behind you and stay seated, upright and still. The chair (scene.chair: its position is the centre of its footprint on the…Sit down on the chair behind you and stay seated, upright and still. The chair (scene.chair: its position is the centre of its footprint on the floor) has a 0.42 x 0.42 m seat 0.475 m high and a backrest on its -x side; its seat centre is 0.25 m behind the robot's start position. HumanoidBench's sit reward is the product of: small control, not moving, upright (torso within about 18 degrees of vertical), a seated posture (head 0.35-0.45 m above the torso's IMU, which holds whenever the torso is upright) and 0.5 x sitting (pelvis 0.68-0.72 m above the floor) + 0.5 x on the chair (pelvis x within 0.19 m of the chair's x, and pelvis y at the chair's y: the term falls to 0.1 at 0.1 m sideways).
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
humanoidbench-standStand upright and still. HumanoidBench's stand reward is the product of: standing (head at least 1.65 m above the floor), upright (torso…Stand upright and still. HumanoidBench's stand reward is the product of: standing (head at least 1.65 m above the floor), upright (torso vertical), small control (small joint forces) and not moving (centre-of-mass speed near zero).
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
humanoidbench-walkWalk forward along +x at 1 m/s or faster while staying upright. HumanoidBench's walk reward is the product of: standing (head at least 1.65 m…Walk forward along +x at 1 m/s or faster while staying upright. HumanoidBench's walk reward is the product of: standing (head at least 1.65 m above the floor), upright, small control, and moving (the centre of mass's world-x velocity: 1 when it is at least 1 m/s, falling linearly to 1/6 at 0 m/s). Only the velocity along the world x axis counts, so keep the heading near 0.
Unitree H1 humanoid with two Shadow hands1,000 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.