farama-foundation/gymnasium-robotics
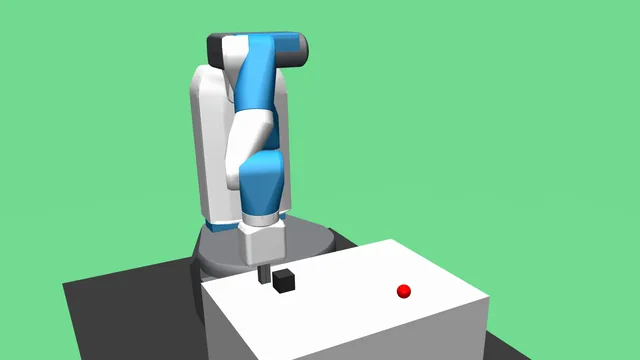
Fetch reach, push and pick-and-place, and PointMaze.
bench eval run \
  -d farama-foundation/gymnasium-robotics@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Fetch arm, Point mass
- Simulator
- Gymnasium-Robotics 1.4.2
- Requirements
- CPU only · 1.1 GB image ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from Gymnasium-Robotics by Farama Foundation, MIT
@misc{robouse_farama_foundation_gymnasium_robotics_0_1,
  title        = {Robo Use farama-foundation/gymnasium-robotics 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/farama-foundation/gymnasium-robotics/}},
  note         = {BenchFlow dataset, tag farama-foundation/gymnasium-robotics-v0.1, commit 9e672aa1e7f0; adapted from Gymnasium-Robotics (Farama Foundation)}
}12 tasks
Embodiment
Task type
Size
Step budget
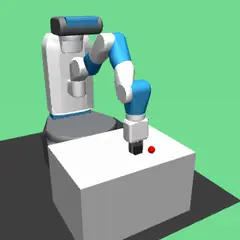
gymrobotics-fetch-pick-place-s0Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there.Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there.
Fetch arm300 stepsjudged on the final state
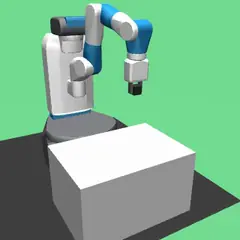
gymrobotics-fetch-pick-place-s1Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there.Pick up the block and place it at the goal position. The goal may be on the table or in the air; if it is in the air, hold the block there.
Fetch arm300 stepsjudged on the final state
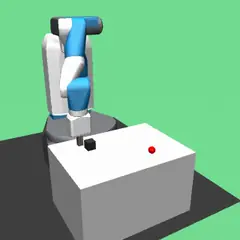
gymrobotics-fetch-push-s0Push the block across the table so it rests on the goal position.
Fetch arm300 stepsjudged on the final state
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 46 | 60 s | Trial |
| Kimi K3 · Claude Code | Solved | 90 | 2 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 55 | 4 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 104 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 89 | 69 s | Trial |
| Opus 5.5 · Claude Code | Solved | 41 | 38 s | Trial |
| GLM-5.3 · Codex | Not solved | 300 | 4 min | Trial |
gymrobotics-fetch-push-s1Push the block across the table so it rests on the goal position.
Fetch arm300 stepsjudged on the final state
gymrobotics-fetch-reach-s0Move the gripper to the goal position and hold it there.
Fetch arm300 stepsjudged on the final state
gymrobotics-fetch-reach-s1Move the gripper to the goal position and hold it there.
Fetch arm300 stepsjudged on the final state
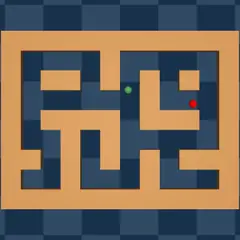
gymrobotics-pointmaze-large-s1Roll the ball through the maze to the goal.
Point mass1,500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 364 | 50 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 699 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 702 | 43 s | Trial |
| GLM-5.3 · Claude Code | Solved | 671 | 2 min | Trial |
| Opus 5.5 · Claude Code | Solved | 548 | 33 s | Trial |
| GLM-5.3 · Codex | Solved | 609 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 1,500 | 2 min | Trial |
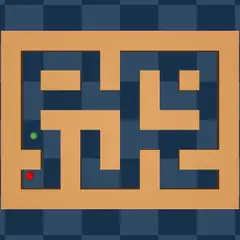
gymrobotics-pointmaze-large-s2Roll the ball through the maze to the goal.
Point mass1,500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 370 | 70 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 950 | 14 min | Trial |
| GLM-5.3 · Claude Code | Solved | 678 | 4 min | Trial |
| Opus 5.5 · Claude Code | Solved | 802 | 46 s | Trial |
| GLM-5.3 · Codex | Solved | 545 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 1,500 | 72 s | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 1,500 | 8 min | Trial |
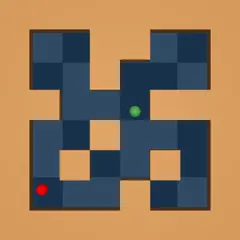
gymrobotics-pointmaze-medium-s3Roll the ball through the maze to the goal.
Point mass1,000 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 224 | 54 s | Trial |
| Kimi K3 · Claude Code | Solved | 428 | 30 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 699 | 58 s | Trial |
| GLM-5.3 · Claude Code | Solved | 494 | 67 s | Trial |
| Opus 5.5 · Claude Code | Solved | 441 | 32 s | Trial |
| GLM-5.3 · Codex | Solved | 719 | 78 s | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 1,000 | 12 min | Trial |
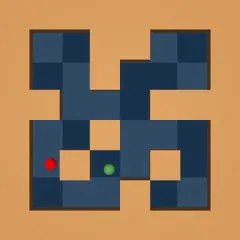
gymrobotics-pointmaze-medium-s5Roll the ball through the maze to the goal.
Point mass1,000 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 297 | 73 s | Trial |
| Kimi K3 · Claude Code | Solved | 611 | 28 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 467 | 90 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 806 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 413 | 90 s | Trial |
| Opus 5.5 · Claude Code | Solved | 632 | 38 s | Trial |
| GLM-5.3 · Codex | Infra failure | 244 | 89 s | Trial |
gymrobotics-pointmaze-umaze-s11Roll the ball through the maze to the goal.
Point mass600 stepsends when first reached
gymrobotics-pointmaze-umaze-s3Roll the ball through the maze to the goal.
Point mass600 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9e672aa1e7f0. The verifier and the reference solution are not published.
Agent harnesses
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| 1 | GLM-5.3 · Claude Code | 100% | 12 of 12 | 12 of 12 |
| 2 | GPT-6 Astra · Codex | 100% | 12 of 12 | 12 of 12 |
| 3 | Opus 5.5 · Claude Code | 100% | 12 of 12 | 12 of 12 |
| 4 | GLM-5.3 · mini-swe-agent | 92% | 11 of 12 | 12 of 12 |
| 5 | Kimi K3 · mini-swe-agent | 92% | 11 of 12 | 12 of 12 |
| 6 | GLM-5.3 · Codex | 91% | 10 of 11 | 12 of 12 · 1 infra |
| 7 | Kimi K3 · Claude Code | 75% | 9 of 12 | 12 of 12 |
Per task
✓ solved ✗ not solved ! infrastructure failure · not run