farama-foundation/metaworld
Meta-World MT50 manipulation on a Sawyer arm.
bench eval run \
  -d farama-foundation/metaworld@0.1 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Sawyer arm
- Simulator
- Meta-World 3.1.1
- Requirements
- CPU only · 1.1 GB image ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from Meta-World by Farama Foundation, MIT
@misc{robouse_farama_foundation_metaworld_0_1,
  title        = {Robo Use farama-foundation/metaworld 0.1},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/farama-foundation/metaworld/}},
  note         = {BenchFlow dataset, tag farama-foundation/metaworld-v0.1, commit 9e672aa1e7f0; adapted from Meta-World (Farama Foundation)}
}50 tasks
metaworld-assemblyPick up the round nut by its handle and place it over the peg.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 152 | 71 s | Trial |
| Opus 5.5 · Claude Code | Solved | 189 | 72 s | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 7 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 492 | 10 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 495 | 5 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 476 | 6 min | Trial |
| GLM-5.3 · Codex | Not solved | 157 | 37 s | Trial |
metaworld-basketballPick up the ball and dunk it into the basketball hoop.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 109 | 54 s | Trial |
| Kimi K3 · Claude Code | Solved | 142 | 38 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 161 | 69 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 161 | 58 s | Trial |
| GLM-5.3 · Claude Code | Solved | 133 | 49 s | Trial |
| Opus 5.5 · Claude Code | Solved | 119 | 45 s | Trial |
| GLM-5.3 · Codex | Infra failure | 145 | 71 s | Trial |
metaworld-bin-pickingPick the cube out of the left bin and place it in the right bin.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 236 | 79 s | Trial |
| Kimi K3 · Claude Code | Solved | 171 | 50 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 288 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 149 | 38 s | Trial |
| GLM-5.3 · Claude Code | Solved | 184 | 69 s | Trial |
| Opus 5.5 · Claude Code | Solved | 170 | 45 s | Trial |
| GLM-5.3 · Codex | Infra failure | 88 | 33 s | Trial |
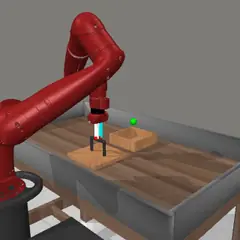
metaworld-box-closePick up the box lid and place it on top of the box.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 112 | 62 s | Trial |
| Kimi K3 · Claude Code | Solved | 141 | 3 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 102 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 141 | 42 s | Trial |
| GLM-5.3 · Claude Code | Solved | 111 | 90 s | Trial |
| Opus 5.5 · Claude Code | Solved | 133 | 48 s | Trial |
| GLM-5.3 · Codex | Infra failure | 35 | 21 s | Trial |
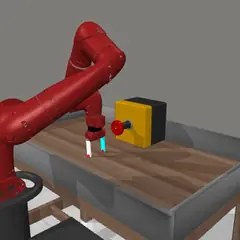
metaworld-button-pressPress the button on the wall panel by pushing it horizontally.
Sawyer arm500 stepsends when first reached
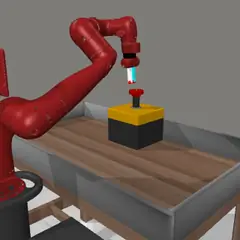
metaworld-button-press-topdownPress the button down from above.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 103 | 32 s | Trial |
| Kimi K3 · Claude Code | Solved | 82 | 34 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 75 | 59 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 115 | 16 s | Trial |
| GLM-5.3 · Claude Code | Solved | 92 | 17 s | Trial |
| Opus 5.5 · Claude Code | Solved | 79 | 14 s | Trial |
| GLM-5.3 · Codex | Solved | 64 | 27 s | Trial |
| MolmoAct2-LIBERO · VLA | Not solved | 500 | 4 min | Trial |
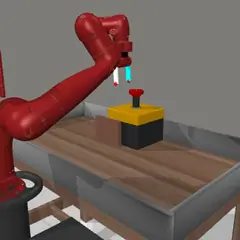
metaworld-button-press-topdown-wallPress the button down from above; a short wall stands in front of it.
Sawyer arm500 stepsends when first reached
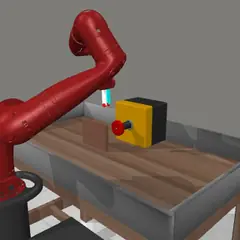
metaworld-button-press-wallPress the button horizontally; reach it past the short wall in front of it.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 81 | 38 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 105 | 63 s | Trial |
| GLM-5.3 · Claude Code | Solved | 349 | 3 min | Trial |
| Opus 5.5 · Claude Code | Solved | 135 | 31 s | Trial |
| GLM-5.3 · Codex | Solved | 102 | 41 s | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 496 | 3 min | Trial |
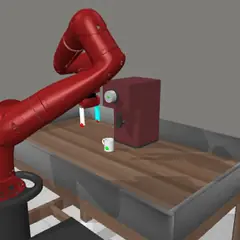
metaworld-coffee-buttonPress the button on the coffee machine.
Sawyer arm500 stepsends when first reached
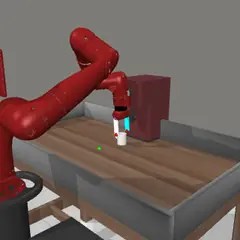
metaworld-coffee-pullPull the mug out from under the coffee machine to the target.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 104 | 25 s | Trial |
| Kimi K3 · Claude Code | Solved | 155 | 2 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 481 | 8 min | Trial |
| Opus 5.5 · Claude Code | Solved | 104 | 18 s | Trial |
| GLM-5.3 · Codex | Solved | 104 | 36 s | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 500 | 4 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 500 | 11 min | Trial |
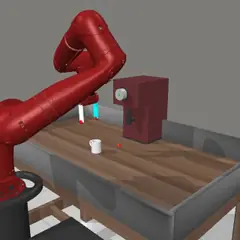
metaworld-coffee-pushPush the mug under the coffee machine to the target.
Sawyer arm500 stepsends when first reached
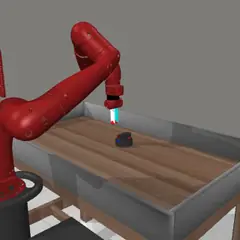
metaworld-dial-turnRotate the dial by pushing its handle around.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 103 | 41 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 346 | 8 min | Trial |
| Opus 5.5 · Claude Code | Solved | 113 | 68 s | Trial |
| Kimi K3 · Claude Code | Not solved | 231 | 15 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 500 | 9 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 284 | 15 min | Trial |
| GLM-5.3 · Codex | Not solved | 500 | 4 min | Trial |
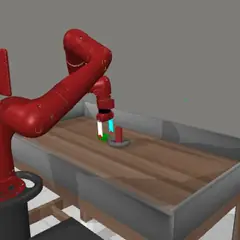
metaworld-disassemblePick the nut off the peg by its handle and lift it clear.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 118 | 27 s | Trial |
| Kimi K3 · Claude Code | Solved | 106 | 87 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 171 | 5 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 145 | 81 s | Trial |
| Opus 5.5 · Claude Code | Solved | 114 | 26 s | Trial |
| GLM-5.3 · Codex | Solved | 243 | 69 s | Trial |
| GLM-5.3 · Claude Code | Not solved | 180 | 2 min | Trial |
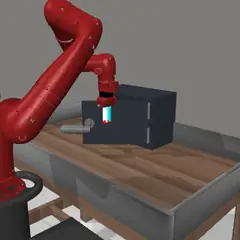
metaworld-door-closeClose the open door by pushing it shut.
Sawyer arm500 stepsends when first reached
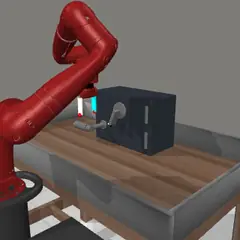
metaworld-door-lockLock the door by turning the lock knob down.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 172 | 46 s | Trial |
| Kimi K3 · Claude Code | Solved | 244 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 407 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 206 | 2 min | Trial |
| Opus 5.5 · Claude Code | Solved | 163 | 45 s | Trial |
| GLM-5.3 · Codex | Solved | 133 | 41 s | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 11 min | Trial |
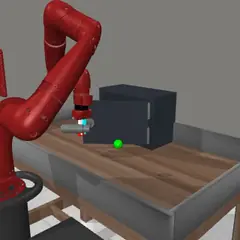
metaworld-door-openOpen the door by pulling its handle.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 263 | 52 s | Trial |
| Kimi K3 · Claude Code | Solved | 220 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 190 | 2 min | Trial |
| GLM-5.3 · Claude Code | Solved | 205 | 59 s | Trial |
| Opus 5.5 · Claude Code | Solved | 190 | 51 s | Trial |
| GLM-5.3 · Codex | Solved | 494 | 3 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 12 min | Trial |
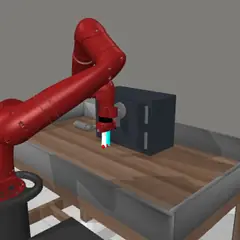
metaworld-door-unlockUnlock the door by turning the lock knob.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 77 | 42 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 353 | 2 min | Trial |
| GLM-5.3 · Claude Code | Solved | 294 | 4 min | Trial |
| Opus 5.5 · Claude Code | Solved | 53 | 24 s | Trial |
| GLM-5.3 · Codex | Solved | 235 | 55 s | Trial |
| Kimi K3 · Claude Code | Not solved | 482 | 15 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 494 | 6 min | Trial |
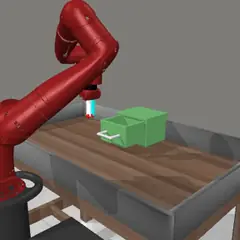
metaworld-drawer-closePush the drawer closed.
Sawyer arm500 stepsends when first reached
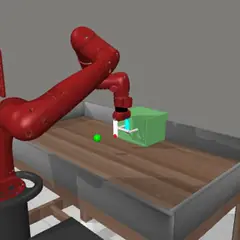
metaworld-drawer-openPull the drawer open by its handle.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 218 | 57 s | Trial |
| Kimi K3 · Claude Code | Solved | 68 | 80 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 93 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 123 | 66 s | Trial |
| GLM-5.3 · Claude Code | Solved | 94 | 31 s | Trial |
| Opus 5.5 · Claude Code | Solved | 158 | 31 s | Trial |
| GLM-5.3 · Codex | Solved | 124 | 26 s | Trial |
| MolmoAct2-LIBERO · VLA | Not solved | 500 | 7 min | Trial |
metaworld-faucet-closeTurn the faucet handle to close it.
Sawyer arm500 stepsends when first reached
metaworld-faucet-openTurn the faucet handle to open it.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 132 | 34 s | Trial |
| Kimi K3 · Claude Code | Solved | 75 | 52 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 236 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 82 | 2 min | Trial |
| Opus 5.5 · Claude Code | Solved | 79 | 24 s | Trial |
| GLM-5.3 · Codex | Solved | 257 | 45 s | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 8 min | Trial |
metaworld-hammerPick up the hammer and use it to hammer the nail into the wall.
Sawyer arm500 stepsends when first reached
metaworld-hand-insertPush or carry the block into the hole in the table (the block must end within 5 cm of the hole).
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 137 | 36 s | Trial |
| Kimi K3 · Claude Code | Solved | 205 | 82 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 146 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 147 | 64 s | Trial |
| GLM-5.3 · Claude Code | Solved | 115 | 28 s | Trial |
| Opus 5.5 · Claude Code | Solved | 155 | 20 s | Trial |
| GLM-5.3 · Codex | Infra failure | 79 | 35 s | Trial |
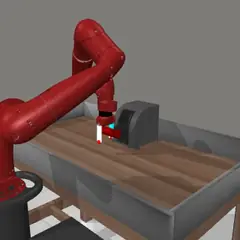
metaworld-handle-pressPress the handle down.
Sawyer arm500 stepsends when first reached
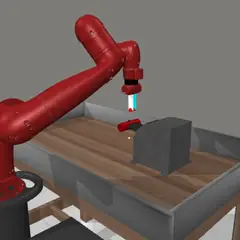
metaworld-handle-press-sidePress the handle down, approaching from the side.
Sawyer arm500 stepsends when first reached
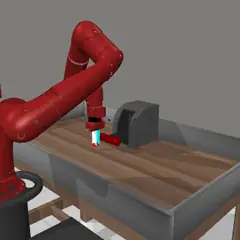
metaworld-handle-pullPull the handle up.
Sawyer arm500 stepsends when first reached
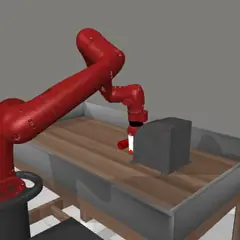
metaworld-handle-pull-sidePull the handle up, approaching from the side.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 80 | 37 s | Trial |
| Kimi K3 · Claude Code | Solved | 202 | 4 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 91 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 134 | 80 s | Trial |
| Opus 5.5 · Claude Code | Solved | 473 | 51 s | Trial |
| GLM-5.3 · Codex | Solved | 192 | 47 s | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 491 | 3 min | Trial |
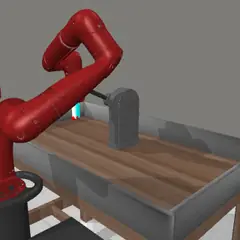
metaworld-lever-pullPull the lever up to the goal.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 102 | 34 s | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 3 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 12 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 479 | 7 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 471 | 6 min | Trial |
| Opus 5.5 · Claude Code | Not solved | 500 | 32 s | Trial |
| GLM-5.3 · Codex | Not solved | 469 | 2 min | Trial |
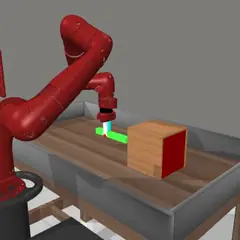
metaworld-peg-insert-sidePick up the peg and insert it sideways into the hole in the box.
Sawyer arm500 stepsends when first reached
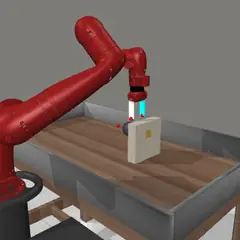
metaworld-peg-unplug-sidePull the peg out sideways from the hole in the box.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 98 | 31 s | Trial |
| Kimi K3 · Claude Code | Solved | 105 | 69 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 82 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 373 | 3 min | Trial |
| Opus 5.5 · Claude Code | Solved | 79 | 22 s | Trial |
| GLM-5.3 · Codex | Solved | 86 | 30 s | Trial |
| GLM-5.3 · Claude Code | Not solved | 499 | 10 min | Trial |
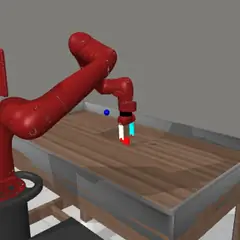
metaworld-pick-out-of-holePick the peg out of the hole and lift it to the goal.
Sawyer arm500 stepsends when first reached
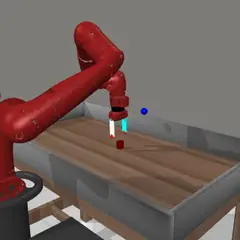
metaworld-pick-placePick up the puck and place it at the goal (the goal is in the air).
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 108 | 29 s | Trial |
| Kimi K3 · Claude Code | Solved | 120 | 21 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 110 | 53 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 135 | 22 s | Trial |
| GLM-5.3 · Claude Code | Solved | 114 | 33 s | Trial |
| Opus 5.5 · Claude Code | Solved | 104 | 22 s | Trial |
| GLM-5.3 · Codex | Solved | 136 | 29 s | Trial |
| pi0.5-LIBERO · VLA | Not solved | 499 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Not solved | 499 | 31 s | Trial |
| MolmoAct2-LIBERO · VLA | Not solved | 500 | 7 min | Trial |
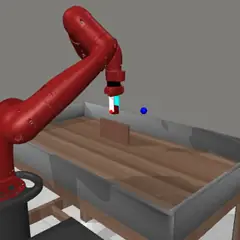
metaworld-pick-place-wallPick up the puck and place it at the goal on the other side of a wall.
Sawyer arm500 stepsends when first reached
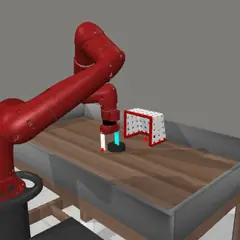
metaworld-plate-slideSlide the plate into the goal net.
Sawyer arm500 stepsends when first reached
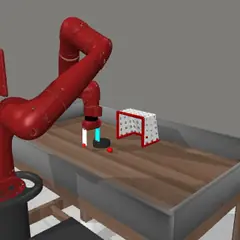
metaworld-plate-slide-backSlide the plate back out of the net to the goal.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GLM-5.3 · mini-swe-agent | Solved | 432 | 4 min | Trial |
| Opus 5.5 · Claude Code | Solved | 198 | 24 s | Trial |
| GPT-6 Astra · Codex | Not solved | 496 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 6 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 7 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 494 | 5 min | Trial |
| GLM-5.3 · Codex | Not solved | 500 | 2 min | Trial |
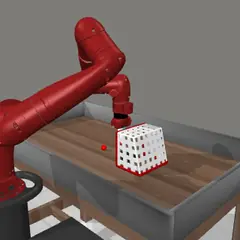
metaworld-plate-slide-back-sideSlide the plate sideways out of the net to the goal.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 325 | 87 s | Trial |
| Opus 5.5 · Claude Code | Solved | 117 | 30 s | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 4 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 10 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 488 | 3 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 484 | 3 min | Trial |
| GLM-5.3 · Codex | Not solved | 500 | 66 s | Trial |
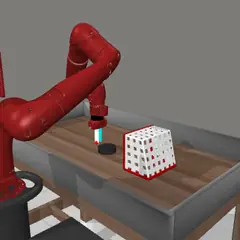
metaworld-plate-slide-sideSlide the plate sideways into the goal net.
Sawyer arm500 stepsends when first reached
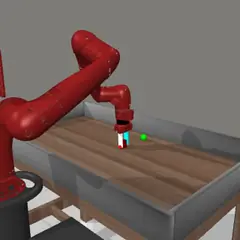
metaworld-pushPush the puck to the goal on the table.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 83 | 33 s | Trial |
| Kimi K3 · Claude Code | Solved | 73 | 22 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 112 | 50 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 78 | 28 s | Trial |
| GLM-5.3 · Claude Code | Solved | 69 | 65 s | Trial |
| Opus 5.5 · Claude Code | Solved | 89 | 18 s | Trial |
| GLM-5.3 · Codex | Solved | 47 | 21 s | Trial |
| pi0.5-LIBERO · VLA | Not solved | 499 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Not solved | 499 | 32 s | Trial |
| MolmoAct2-LIBERO · VLA | Not solved | 500 | 6 min | Trial |
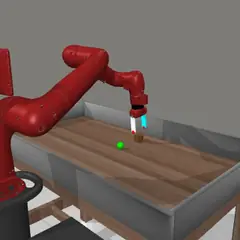
metaworld-push-backPull the puck back toward the robot to the goal.
Sawyer arm500 stepsends when first reached
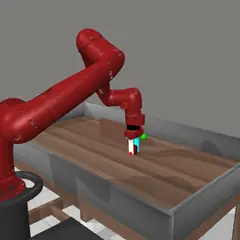
metaworld-push-wallPush the puck to the goal, around the wall between them.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| Opus 5.5 · Claude Code | Solved | 159 | 23 s | Trial |
| GPT-6 Astra · Codex | Not solved | 500 | 3 min | Trial |
| Kimi K3 · Claude Code | Not solved | 470 | 6 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 12 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 500 | 4 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 466 | 9 min | Trial |
| GLM-5.3 · Codex | Not solved | 489 | 3 min | Trial |
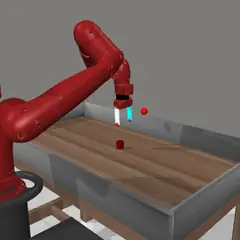
metaworld-reachMove the gripper to the goal position.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 36 | 20 s | Trial |
| Kimi K3 · Claude Code | Solved | 36 | 12 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 36 | 13 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 34 | 14 s | Trial |
| GLM-5.3 · Claude Code | Solved | 36 | 11 s | Trial |
| Opus 5.5 · Claude Code | Solved | 36 | 10 s | Trial |
| GLM-5.3 · Codex | Solved | 36 | 16 s | Trial |
| pi0.5-LIBERO · VLA | Not solved | 499 | 32 s | Trial |
| GR00T N1.7-LIBERO · VLA | Not solved | 499 | 31 s | Trial |
| MolmoAct2-LIBERO · VLA | Not solved | 500 | 2 min | Trial |
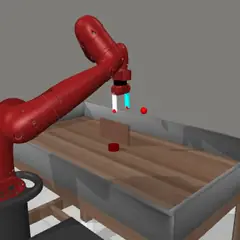
metaworld-reach-wallMove the gripper to the goal position, reaching over the wall.
Sawyer arm500 stepsends when first reached
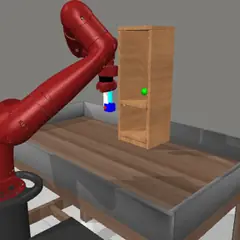
metaworld-shelf-placePick up the block and place it on the shelf at the goal.
Sawyer arm500 stepsends when first reached
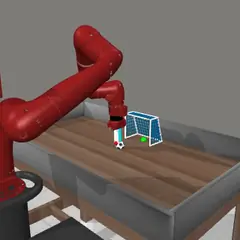
metaworld-soccerPush the ball into the goal.
Sawyer arm500 stepsends when first reached
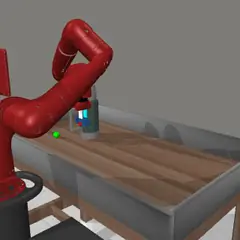
metaworld-stick-pullPick up the stick and use it to pull the thermos to the goal.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Not solved | 500 | 3 min | Trial |
| Kimi K3 · Claude Code | Not solved | 384 | 4 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 500 | 10 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 237 | 8 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 485 | 7 min | Trial |
| Opus 5.5 · Claude Code | Not solved | 164 | 46 s | Trial |
| GLM-5.3 · Codex | Infra failure | 41 | 26 s | Trial |
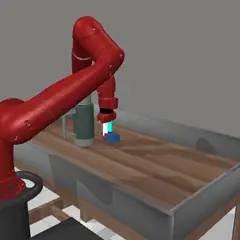
metaworld-stick-pushPick up the stick and use it to push the thermos to the goal.
Sawyer arm500 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 125 | 2 min | Trial |
| Kimi K3 · Claude Code | Solved | 131 | 31 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 355 | 14 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 378 | 2 min | Trial |
| GLM-5.3 · Claude Code | Solved | 169 | 55 s | Trial |
| Opus 5.5 · Claude Code | Solved | 134 | 30 s | Trial |
| GLM-5.3 · Codex | Not solved | 219 | 74 s | Trial |
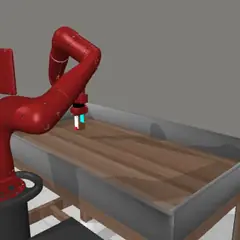
metaworld-sweepSweep the puck off the edge of the table.
Sawyer arm500 stepsends when first reached
metaworld-sweep-intoSweep the puck into the hole in the table.
Sawyer arm500 stepsends when first reached
metaworld-window-closeSlide the window closed by pushing its handle sideways.
Sawyer arm500 stepsends when first reached
metaworld-window-openSlide the window open by pushing its handle sideways.
Sawyer arm500 stepsends when first reached
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit 9e672aa1e7f0. The verifier and the reference solution are not published.
Agent harnesses
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| 1 | Opus 5.5 · Claude Code | 96% | 48 of 50 | 50 of 50 |
| 2 | GPT-6 Astra · Codex | 94% | 47 of 50 | 50 of 50 |
| 3 | GLM-5.3 · Codex | 84% | 38 of 45 | 50 of 50 · 5 infra |
| 4 | GLM-5.3 · mini-swe-agent | 82% | 41 of 50 | 50 of 50 |
| 5 | Kimi K3 · Claude Code | 82% | 41 of 50 | 50 of 50 |
| 6 | GLM-5.3 · Claude Code | 80% | 40 of 50 | 50 of 50 |
| 7 | Kimi K3 · mini-swe-agent | 80% | 40 of 50 | 50 of 50 |
VLA policies
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| Zero-shot probe (ranked on lifelong-robot-learning/libero), not ranked here | ||||
| MolmoAct2-LIBERO · VLA | 0% | 0 of 5 | 5 of 50 | |
| GR00T N1.7-LIBERO · VLA | 0% | 0 of 3 | 3 of 50 | |
| pi0.5-LIBERO · VLA | 0% | 0 of 3 | 3 of 50 | |
Per task
✓ solved ✗ not solved ! infrastructure failure · not run