lifelong-robot-learning/libero
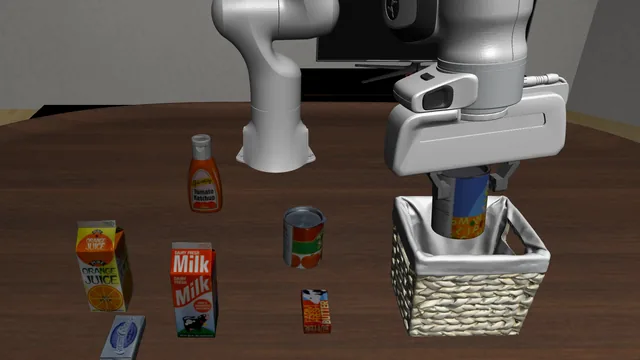
LIBERO's four standard suites on a Franka Panda.
bench eval run \
  -d lifelong-robot-learning/libero@0.2 \
  --registry https://robouse.ai/hub/registry.json \
--agent oracleAbout this dataset
- Embodiment
- Franka Panda
- Simulator
- LIBERO (robosuite 1.4)
- Requirements
- CPU only · 4.0 GB image · 4 GB memory ·
bench>=0.7.4,<0.8 - Licence
- Task packages Apache-2.0; adapted from LIBERO by Lifelong Robot Learning, MIT
@misc{robouse_lifelong_robot_learning_libero_0_2,
  title        = {Robo Use lifelong-robot-learning/libero 0.2},
  author       = {{BenchFlow}},
  year         = {2026},
  howpublished = {\url{https://robouse.ai/hub/lifelong-robot-learning/libero/}},
  note         = {BenchFlow dataset, tag lifelong-robot-learning/libero-v0.2, commit bcd0d002b9df; adapted from LIBERO (Lifelong Robot Learning)}
}40 tasks
Size
Step budget
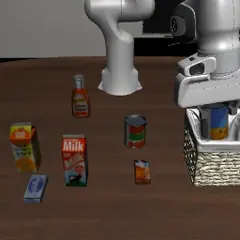
libero-10-0A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task LIVING_ROOM_SCENE2_put_both_the_alphabet_soup_and_the_tomato_sauce_in_the_basket). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 364 | 2 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 279 | 76 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 408 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 455 | 4 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 269 | 43 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 286 | 39 s | Trial |
| EVO1-LIBERO · VLA | Solved | 278 | 3 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 282 | 23 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 266 | 46 s | Trial |
| pi0-LIBERO · VLA | Solved | 279 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 371 | 72 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 508 | 75 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 253 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 518 | 9 min | Trial |
| GLM-5.3 · Codex | Not solved | 520 | 3 min | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 70 s | Trial |
| Opus 5.5 · Claude Code | Stopped, not scored | · | · | Trial |
libero-10-1A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task LIVING_ROOM_SCENE2_put_both_the_cream_cheese_box_and_the_butter_in_the_basket). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 239 | 43 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 358 | 46 s | Trial |
| EVO1-LIBERO · VLA | Solved | 252 | 59 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 235 | 23 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 252 | 42 s | Trial |
| pi0-LIBERO · VLA | Solved | 244 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 253 | 57 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 240 | 45 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 240 | 39 s | Trial |
libero-10-2A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task KITCHEN_SCENE3_turn_on_the_stove_and_put_the_moka_pot_on_it). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 362 | 3 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 275 | 41 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 269 | 38 s | Trial |
| EVO1-LIBERO · VLA | Solved | 258 | 59 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 237 | 23 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 261 | 43 s | Trial |
| pi0-LIBERO · VLA | Solved | 244 | 29 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 243 | 46 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 269 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Solved | 240 | 37 s | Trial |
| Kimi K3 · Claude Code | Not solved | 500 | 10 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 519 | 16 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 496 | 13 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 504 | 8 min | Trial |
| GLM-5.3 · Codex | Not solved | 520 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 519 | 84 s | Trial |
| Opus 5.5 · Claude Code | Stopped, not scored | · | · | Trial |
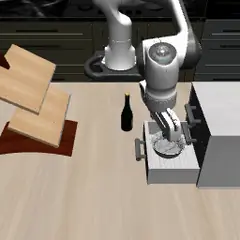
libero-10-3A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task KITCHEN_SCENE4_put_the_black_bowl_in_the_bottom_drawer_of_the_cabinet_and_close_it). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 206 | 35 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 230 | 34 s | Trial |
| EVO1-LIBERO · VLA | Solved | 216 | 6 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 206 | 2 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 285 | 44 s | Trial |
| pi0-LIBERO · VLA | Solved | 206 | 32 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 262 | 55 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 227 | 48 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 209 | 36 s | Trial |
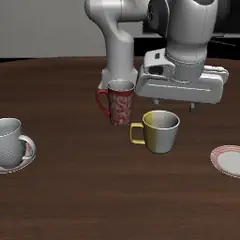
libero-10-4A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task LIVING_ROOM_SCENE5_put_the_white_mug_on_the_left_plate_and_put_the_yellow_and_white_mug_on_the_right_plate). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 330 | 2 min | Trial |
| Kimi K3 · Claude Code | Solved | 444 | 10 min | Trial |
| GLM-5.3 · Claude Code | Solved | 263 | 7 min | Trial |
| GLM-5.3 · Codex | Solved | 220 | 2 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 241 | 4 min | Trial |
| EVO1-LIBERO · VLA | Solved | 220 | 6 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 218 | 2 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 218 | 39 s | Trial |
| pi0-LIBERO · VLA | Solved | 244 | 46 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 242 | 54 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 219 | 2 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 520 | 17 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 520 | 11 min | Trial |
| GR00T N1.7-LIBERO · VLA | Not solved | 519 | 56 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 519 | 73 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 66 s | Trial |
| Opus 5.5 · Claude Code | Stopped, not scored | · | · | Trial |
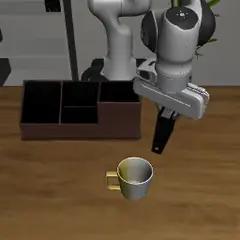
libero-10-5A Franka Panda arm with a parallel-jaw gripper works at a desk in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a desk in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task STUDY_SCENE1_pick_up_the_book_and_place_it_in_the_back_compartment_of_the_caddy). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 151 | 4 min | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 266 | 35 s | Trial |
| EVO1-LIBERO · VLA | Solved | 204 | 4 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 195 | 2 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 251 | 37 s | Trial |
| pi0-LIBERO · VLA | Solved | 234 | 43 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 291 | 48 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 519 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 61 s | Trial |
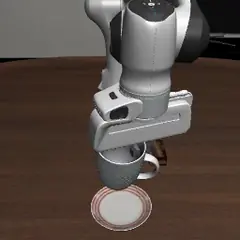
libero-10-6A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task LIVING_ROOM_SCENE6_put_the_white_mug_on_the_plate_and_put_the_chocolate_pudding_to_the_right_of_the_plate). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 442 | 2 min | Trial |
| Kimi K3 · Claude Code | Solved | 429 | 4 min | Trial |
| GLM-5.3 · Claude Code | Solved | 470 | 10 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 198 | 4 min | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 247 | 31 s | Trial |
| EVO1-LIBERO · VLA | Solved | 203 | 16 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 195 | 84 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 291 | 40 s | Trial |
| pi0-LIBERO · VLA | Solved | 218 | 46 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 212 | 65 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 239 | 55 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 204 | 2 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 515 | 18 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 520 | 10 min | Trial |
| GLM-5.3 · Codex | Not solved | 380 | 6 min | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 61 s | Trial |
| Opus 5.5 · Claude Code | Stopped, not scored | · | · | Trial |
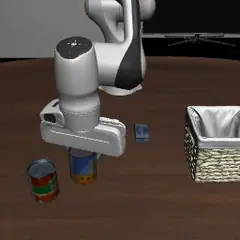
libero-10-7A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a low table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task LIVING_ROOM_SCENE1_put_both_the_alphabet_soup_and_the_cream_cheese_box_in_the_basket). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 237 | 4 min | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 296 | 40 s | Trial |
| EVO1-LIBERO · VLA | Solved | 255 | 16 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 246 | 2 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 240 | 36 s | Trial |
| pi0-LIBERO · VLA | Solved | 296 | 57 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 257 | 69 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 519 | 88 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 63 s | Trial |
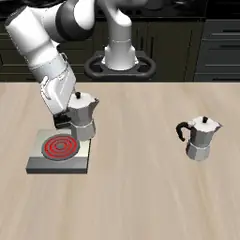
libero-10-8A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task KITCHEN_SCENE8_put_both_moka_pots_on_the_stove). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 434 | 60 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 407 | 46 s | Trial |
| EVO1-LIBERO · VLA | Solved | 356 | 17 min | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 364 | 2 min | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 352 | 3 min | Trial |
| GPT-6 Astra · Codex | Not solved | 518 | 3 min | Trial |
| Kimi K3 · Claude Code | Not solved | 440 | 30 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 520 | 24 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 520 | 14 min | Trial |
| GLM-5.3 · Codex | Not solved | 514 | 7 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Not solved | 519 | 54 s | Trial |
| pi0-LIBERO · VLA | Not solved | 519 | 81 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 519 | 85 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 519 | 87 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 64 s | Trial |
| GLM-5.3 · mini-swe-agent | Infra failure | 448 | 20 min | Trial |
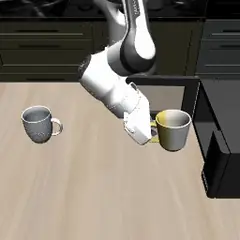
libero-10-9A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_10, task KITCHEN_SCENE6_put_the_yellow_and_white_mug_in_the_microwave_and_close_it). LIBERO-Long (libero_10): long-horizon tasks, most with two sub-goals.
Franka Panda520 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 241 | 43 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 237 | 34 s | Trial |
| EVO1-LIBERO · VLA | Solved | 236 | 48 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 238 | 2 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 229 | 30 s | Trial |
| pi0-LIBERO · VLA | Solved | 250 | 59 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 213 | 27 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 519 | 67 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 519 | 64 s | Trial |
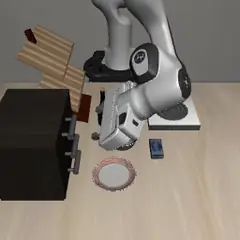
libero-goal-0A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task open_the_middle_drawer_of_the_cabinet). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 205 | 2 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 131 | 34 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 127 | 27 s | Trial |
| EVO1-LIBERO · VLA | Solved | 118 | 33 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 133 | 70 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 114 | 23 s | Trial |
| pi0-LIBERO · VLA | Solved | 110 | 43 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 138 | 28 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 129 | 52 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 144 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Solved | 169 | 30 s | Trial |
| Kimi K3 · Claude Code | Not solved | 158 | 20 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 300 | 15 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 300 | 4 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 300 | 6 min | Trial |
| GLM-5.3 · Codex | Not solved | 300 | 86 s | Trial |
libero-goal-1A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_bowl_on_the_stove). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 79 | 28 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 90 | 24 s | Trial |
| EVO1-LIBERO · VLA | Solved | 83 | 29 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 76 | 38 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 73 | 20 s | Trial |
| pi0-LIBERO · VLA | Solved | 85 | 37 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 83 | 23 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 90 | 30 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 81 | 22 s | Trial |
libero-goal-2A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_wine_bottle_on_top_of_the_cabinet). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GR00T N1.7-LIBERO · VLA | Solved | 81 | 24 s | Trial |
| EVO1-LIBERO · VLA | Solved | 82 | 55 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 84 | 20 s | Trial |
| pi0-LIBERO · VLA | Solved | 101 | 43 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 94 | 29 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 99 | 30 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 78 | 48 s | Trial |
| GPT-6 Astra · Codex | Not solved | 300 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 300 | 16 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 300 | 11 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 300 | 8 min | Trial |
| GLM-5.3 · Codex | Not solved | 300 | 3 min | Trial |
| pi0.5-LIBERO · VLA | Not solved | 299 | 52 s | Trial |
| VLA-JEPA-LIBERO · VLA | Not solved | 299 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 299 | 44 s | Trial |
| GLM-5.3 · mini-swe-agent | Infra failure | 262 | 15 min | Trial |
libero-goal-3A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task open_the_top_drawer_and_put_the_bowl_inside). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 169 | 40 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 162 | 29 s | Trial |
| EVO1-LIBERO · VLA | Solved | 174 | 70 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 213 | 85 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 219 | 30 s | Trial |
| pi0-LIBERO · VLA | Solved | 190 | 42 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 186 | 34 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 173 | 32 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 179 | 32 s | Trial |
libero-goal-4A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_bowl_on_top_of_the_cabinet). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| Kimi K3 · Claude Code | Solved | 298 | 6 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 81 | 4 min | Trial |
| GLM-5.3 · Claude Code | Solved | 193 | 4 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 76 | 32 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 83 | 23 s | Trial |
| EVO1-LIBERO · VLA | Solved | 79 | 54 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 78 | 42 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 78 | 18 s | Trial |
| pi0-LIBERO · VLA | Solved | 89 | 31 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 88 | 24 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 83 | 31 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 81 | 52 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 82 | 22 s | Trial |
| GPT-6 Astra · Codex | Not solved | 290 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 286 | 6 min | Trial |
| GLM-5.3 · Codex | Not solved | 271 | 2 min | Trial |
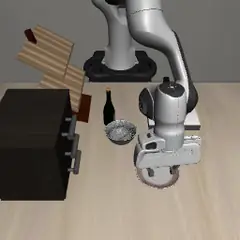
libero-goal-5A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task push_the_plate_to_the_front_of_the_stove). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 117 | 38 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 124 | 26 s | Trial |
| EVO1-LIBERO · VLA | Solved | 138 | 40 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 148 | 62 s | Trial |
| pi0-LIBERO · VLA | Solved | 131 | 28 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 141 | 38 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 120 | 30 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 268 | 42 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Not solved | 299 | 43 s | Trial |
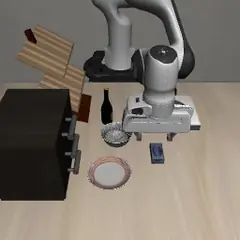
libero-goal-6A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_cream_cheese_in_the_bowl). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 181 | 61 s | Trial |
| Kimi K3 · Claude Code | Solved | 192 | 78 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 171 | 80 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 91 | 40 s | Trial |
| GLM-5.3 · Claude Code | Solved | 196 | 85 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 89 | 43 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 80 | 20 s | Trial |
| EVO1-LIBERO · VLA | Solved | 84 | 28 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 79 | 39 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 77 | 38 s | Trial |
| pi0-LIBERO · VLA | Solved | 94 | 26 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 86 | 26 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 83 | 45 s | Trial |
| GLM-5.3 · Codex | Not solved | 293 | 2 min | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 299 | 46 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 299 | 72 s | Trial |
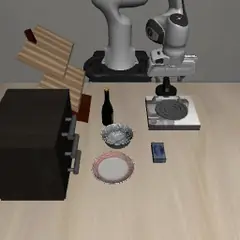
libero-goal-7A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task turn_on_the_stove). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 63 | 40 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 70 | 20 s | Trial |
| EVO1-LIBERO · VLA | Solved | 71 | 30 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 68 | 33 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 73 | 39 s | Trial |
| pi0-LIBERO · VLA | Solved | 61 | 27 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 74 | 33 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 76 | 25 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 70 | 19 s | Trial |
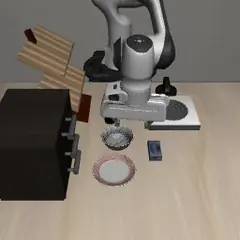
libero-goal-8A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_bowl_on_the_plate). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| Kimi K3 · Claude Code | Solved | 254 | 5 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 194 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 283 | 3 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 66 | 42 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 72 | 21 s | Trial |
| EVO1-LIBERO · VLA | Solved | 149 | 35 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 68 | 34 s | Trial |
| pi0-LIBERO · VLA | Solved | 74 | 30 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 257 | 58 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 70 | 38 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 73 | 47 s | Trial |
| GPT-6 Astra · Codex | Not solved | 272 | 2 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 299 | 19 min | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Not solved | 299 | 55 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 299 | 40 s | Trial |
| GLM-5.3 · Codex | Infra failure | 72 | 51 s | Trial |
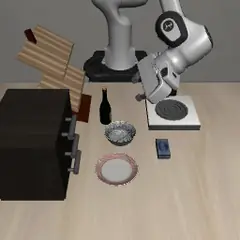
libero-goal-9A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_goal, task put_the_wine_bottle_on_the_rack). LIBERO-Goal: one fixed kitchen scene; the instruction sets the goal.
Franka Panda300 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 136 | 47 s | Trial |
| EVO1-LIBERO · VLA | Solved | 133 | 33 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 120 | 53 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 128 | 30 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 147 | 43 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 141 | 50 s | Trial |
| GR00T N1.7-LIBERO · VLA | Not solved | 299 | 35 s | Trial |
| pi0-LIBERO · VLA | Not solved | 299 | 55 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 299 | 48 s | Trial |
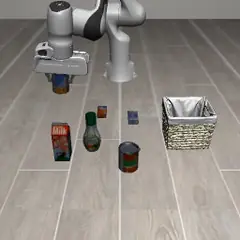
libero-object-0A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_alphabet_soup_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 126 | 53 s | Trial |
| Kimi K3 · Claude Code | Solved | 146 | 64 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 151 | 3 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 147 | 51 s | Trial |
| GLM-5.3 · Claude Code | Solved | 248 | 6 min | Trial |
| GLM-5.3 · Codex | Solved | 156 | 56 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 132 | 46 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 124 | 33 s | Trial |
| EVO1-LIBERO · VLA | Solved | 138 | 35 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 131 | 56 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 131 | 34 s | Trial |
| pi0-LIBERO · VLA | Solved | 151 | 36 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 136 | 48 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 128 | 63 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 197 | 4 min | Trial |
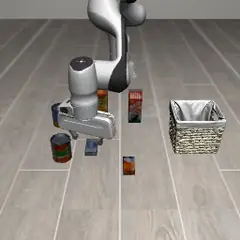
libero-object-1A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_cream_cheese_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 156 | 43 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 133 | 34 s | Trial |
| EVO1-LIBERO · VLA | Solved | 127 | 38 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 122 | 54 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 119 | 28 s | Trial |
| pi0-LIBERO · VLA | Solved | 125 | 31 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 126 | 25 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 128 | 51 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 122 | 16 min | Trial |
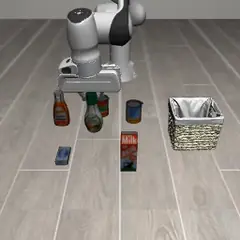
libero-object-2A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_salad_dressing_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 131 | 54 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 144 | 50 s | Trial |
| GLM-5.3 · Claude Code | Solved | 256 | 5 min | Trial |
| GLM-5.3 · Codex | Solved | 207 | 62 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 107 | 38 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 108 | 29 s | Trial |
| EVO1-LIBERO · VLA | Solved | 120 | 36 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 114 | 52 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 114 | 40 s | Trial |
| pi0-LIBERO · VLA | Solved | 112 | 29 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 116 | 23 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 108 | 49 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 115 | 68 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 120 | 4 min | Trial |
| Kimi K3 · Claude Code | Not solved | 280 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 280 | 5 min | Trial |
libero-object-3A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_bbq_sauce_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GR00T N1.7-LIBERO · VLA | Solved | 115 | 28 s | Trial |
| EVO1-LIBERO · VLA | Solved | 120 | 36 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 115 | 53 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 113 | 39 s | Trial |
| pi0-LIBERO · VLA | Solved | 123 | 32 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 121 | 52 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 152 | 4 min | Trial |
| pi0.5-LIBERO · VLA | Not solved | 279 | 54 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 279 | 55 s | Trial |
libero-object-4A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_ketchup_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 142 | 67 s | Trial |
| Kimi K3 · Claude Code | Solved | 160 | 66 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 157 | 69 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 236 | 3 min | Trial |
| GLM-5.3 · Claude Code | Solved | 183 | 57 s | Trial |
| GLM-5.3 · Codex | Solved | 198 | 60 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 136 | 36 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 144 | 31 s | Trial |
| EVO1-LIBERO · VLA | Solved | 138 | 36 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 137 | 59 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 131 | 37 s | Trial |
| pi0-LIBERO · VLA | Solved | 137 | 36 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 150 | 36 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 134 | 45 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 142 | 74 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 131 | 16 min | Trial |
libero-object-5A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_tomato_sauce_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 129 | 35 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 111 | 30 s | Trial |
| EVO1-LIBERO · VLA | Solved | 143 | 35 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 119 | 54 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 124 | 37 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 116 | 30 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 139 | 40 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 169 | 56 s | Trial |
| pi0-LIBERO · VLA | Not solved | 279 | 37 s | Trial |
libero-object-6A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_butter_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 187 | 2 min | Trial |
| Kimi K3 · Claude Code | Solved | 200 | 39 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 207 | 52 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 178 | 75 s | Trial |
| GLM-5.3 · Claude Code | Solved | 152 | 85 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 186 | 37 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 171 | 33 s | Trial |
| EVO1-LIBERO · VLA | Solved | 150 | 47 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 149 | 63 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 149 | 36 s | Trial |
| pi0-LIBERO · VLA | Solved | 144 | 26 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 152 | 33 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 137 | 43 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 163 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Solved | 159 | 52 s | Trial |
| GLM-5.3 · Codex | Not solved | 280 | 73 s | Trial |
libero-object-7A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_milk_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 122 | 32 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 132 | 32 s | Trial |
| EVO1-LIBERO · VLA | Solved | 128 | 31 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 121 | 54 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 139 | 36 s | Trial |
| pi0-LIBERO · VLA | Solved | 121 | 24 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 135 | 31 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 120 | 42 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 122 | 3 min | Trial |
libero-object-8A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_chocolate_pudding_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 127 | 2 min | Trial |
| Kimi K3 · Claude Code | Solved | 190 | 53 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 243 | 90 s | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 152 | 56 s | Trial |
| GLM-5.3 · Claude Code | Solved | 157 | 4 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 161 | 34 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 152 | 34 s | Trial |
| EVO1-LIBERO · VLA | Solved | 149 | 33 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 141 | 71 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 141 | 37 s | Trial |
| pi0-LIBERO · VLA | Solved | 143 | 4 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 151 | 32 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 149 | 62 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 143 | 2 min | Trial |
| SmolVLA-LIBERO · VLA | Solved | 138 | 4 min | Trial |
| GLM-5.3 · Codex | Not solved | 278 | 2 min | Trial |
libero-object-9A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task…A Franka Panda arm with a parallel-jaw gripper works over the floor in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_object, task pick_up_the_orange_juice_and_place_it_in_the_basket). LIBERO-Object: the same layout with different grocery items; pick the named item and put it in the basket.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 117 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 123 | 23 s | Trial |
| EVO1-LIBERO · VLA | Solved | 156 | 33 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 120 | 64 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 113 | 34 s | Trial |
| pi0-LIBERO · VLA | Solved | 116 | 4 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 133 | 34 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 119 | 39 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 129 | 4 min | Trial |
libero-spatial-0A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_between_the_plate_and_the_ramekin_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 195 | 84 s | Trial |
| Kimi K3 · Claude Code | Solved | 277 | 6 min | Trial |
| Kimi K3 · mini-swe-agent | Solved | 227 | 3 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 75 | 28 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 79 | 35 s | Trial |
| EVO1-LIBERO · VLA | Solved | 80 | 24 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 74 | 50 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 75 | 73 s | Trial |
| pi0-LIBERO · VLA | Solved | 77 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 78 | 44 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 77 | 76 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 91 | 38 s | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 280 | 6 min | Trial |
| GLM-5.3 · Codex | Not solved | 274 | 3 min | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 279 | 60 s | Trial |
| GLM-5.3 · Claude Code | Infra failure | 176 | 5 min | Trial |
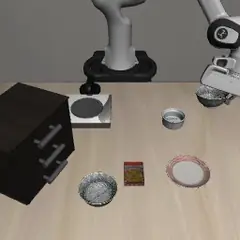
libero-spatial-1A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_next_to_the_ramekin_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 105 | 35 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 103 | 34 s | Trial |
| EVO1-LIBERO · VLA | Solved | 108 | 28 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 107 | 57 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 104 | 67 s | Trial |
| pi0-LIBERO · VLA | Solved | 111 | 2 min | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 108 | 32 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 279 | 75 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 279 | 88 s | Trial |
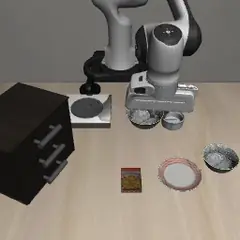
libero-spatial-2A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_from_table_center_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 249 | 75 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 209 | 2 min | Trial |
| GLM-5.3 · Claude Code | Solved | 152 | 8 min | Trial |
| GLM-5.3 · Codex | Solved | 181 | 87 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 96 | 35 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 88 | 35 s | Trial |
| EVO1-LIBERO · VLA | Solved | 89 | 26 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 90 | 49 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 85 | 66 s | Trial |
| pi0-LIBERO · VLA | Solved | 101 | 4 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 91 | 54 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 84 | 30 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 93 | 55 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 90 | 45 s | Trial |
| Kimi K3 · Claude Code | Not solved | 280 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 280 | 5 min | Trial |
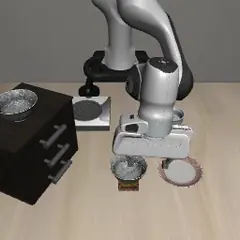
libero-spatial-3A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_on_the_cookie_box_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 85 | 33 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 86 | 40 s | Trial |
| EVO1-LIBERO · VLA | Solved | 87 | 26 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 85 | 65 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 84 | 34 s | Trial |
| pi0-LIBERO · VLA | Solved | 84 | 4 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 86 | 52 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 80 | 30 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 279 | 7 min | Trial |
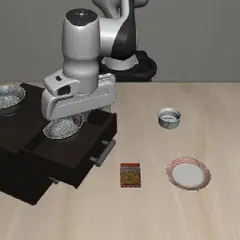
libero-spatial-4A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_in_the_top_drawer_of_the_wooden_cabinet_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 121 | 38 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 117 | 40 s | Trial |
| EVO1-LIBERO · VLA | Solved | 113 | 30 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 111 | 56 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 132 | 37 s | Trial |
| pi0-LIBERO · VLA | Solved | 120 | 4 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 121 | 50 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 122 | 30 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 121 | 64 s | Trial |
| GPT-6 Astra · Codex | Not solved | 280 | 2 min | Trial |
| Kimi K3 · Claude Code | Not solved | 280 | 4 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 280 | 9 min | Trial |
| GLM-5.3 · mini-swe-agent | Not solved | 174 | 6 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 280 | 8 min | Trial |
| GLM-5.3 · Codex | Not solved | 260 | 3 min | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 279 | 7 min | Trial |
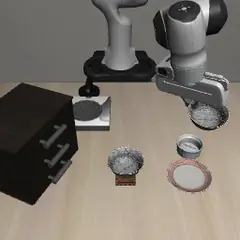
libero-spatial-5A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_on_the_ramekin_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 105 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 125 | 43 s | Trial |
| EVO1-LIBERO · VLA | Solved | 112 | 29 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 89 | 29 s | Trial |
| pi0-LIBERO · VLA | Solved | 96 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 105 | 57 s | Trial |
| VLA-JEPA-LIBERO · VLA | Not solved | 279 | 2 min | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 279 | 43 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 279 | 22 min | Trial |
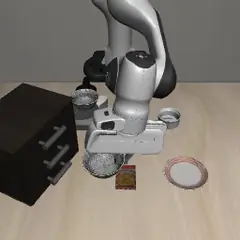
libero-spatial-6A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_next_to_the_cookie_box_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 226 | 81 s | Trial |
| Kimi K3 · Claude Code | Solved | 257 | 4 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 248 | 3 min | Trial |
| GLM-5.3 · Codex | Solved | 205 | 74 s | Trial |
| pi0.5-LIBERO · VLA | Solved | 107 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 125 | 48 s | Trial |
| EVO1-LIBERO · VLA | Solved | 108 | 28 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 102 | 48 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 107 | 26 s | Trial |
| pi0-LIBERO · VLA | Solved | 100 | 3 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 123 | 51 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 104 | 26 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 112 | 59 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 108 | 16 min | Trial |
| Kimi K3 · mini-swe-agent | Not solved | 273 | 5 min | Trial |
| GLM-5.3 · Claude Code | Not solved | 280 | 9 min | Trial |
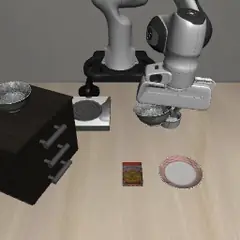
libero-spatial-7A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_on_the_stove_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 121 | 31 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 105 | 50 s | Trial |
| EVO1-LIBERO · VLA | Solved | 108 | 28 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 106 | 51 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 134 | 61 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 119 | 40 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 106 | 16 min | Trial |
| pi0-LIBERO · VLA | Not solved | 279 | 3 min | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 279 | 38 s | Trial |
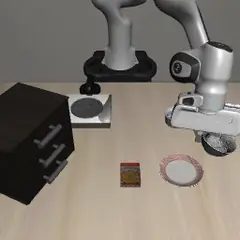
libero-spatial-8A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_next_to_the_plate_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| GPT-6 Astra · Codex | Solved | 201 | 67 s | Trial |
| Kimi K3 · Claude Code | Solved | 255 | 76 s | Trial |
| Kimi K3 · mini-swe-agent | Solved | 215 | 2 min | Trial |
| GLM-5.3 · mini-swe-agent | Solved | 193 | 2 min | Trial |
| GLM-5.3 · Claude Code | Solved | 249 | 5 min | Trial |
| pi0.5-LIBERO · VLA | Solved | 92 | 34 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 99 | 47 s | Trial |
| EVO1-LIBERO · VLA | Solved | 96 | 26 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 91 | 44 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 100 | 61 s | Trial |
| pi0-LIBERO · VLA | Solved | 98 | 45 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Solved | 88 | 22 s | Trial |
| MolmoAct2-LIBERO · VLA | Solved | 92 | 40 s | Trial |
| GLM-5.3 · Codex | Not solved | 279 | 2 min | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Not solved | 279 | 62 s | Trial |
| SmolVLA-LIBERO · VLA | Not solved | 279 | 2 min | Trial |
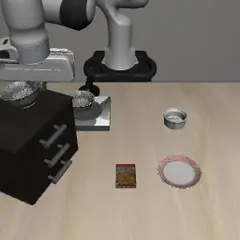
libero-spatial-9A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task…A Franka Panda arm with a parallel-jaw gripper works at a table in a LIBERO scene (MuJoCo / robosuite; LIBERO suite libero_spatial, task pick_up_the_black_bowl_on_the_wooden_cabinet_and_place_it_on_the_plate). LIBERO-Spatial: the same objects in different layouts; the instruction says which of two identical bowls to move.
Franka Panda280 stepsends when first reached
| Model | Result | Steps | Time | Trial |
|---|---|---|---|---|
| pi0.5-LIBERO · VLA | Solved | 117 | 29 s | Trial |
| GR00T N1.7-LIBERO · VLA | Solved | 124 | 29 s | Trial |
| EVO1-LIBERO · VLA | Solved | 116 | 30 s | Trial |
| VLA-JEPA-LIBERO · VLA | Solved | 122 | 54 s | Trial |
| pi0.5-LIBERO (LeRobot) · VLA | Solved | 117 | 42 s | Trial |
| pi0-LIBERO · VLA | Solved | 118 | 42 s | Trial |
| pi0-FAST-LIBERO (LeRobot) · VLA | Solved | 122 | 53 s | Trial |
| SmolVLA-LIBERO · VLA | Solved | 116 | 46 s | Trial |
| pi0-LIBERO (LeRobot) · VLA | Not solved | 279 | 38 s | Trial |
↑ ↓ move between rows · Enter shows details · O opens the task
Each task is a package in the task format, pinned to robohub commit bcd0d002b9df. The verifier and the reference solution are not published.
Agent harnesses
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| 1 | GPT-6 Astra · Codex | 75% | 15 of 20 | 20 of 40 |
| 2 | GLM-5.3 · Claude Code | 63% | 12 of 19 | 20 of 40 · 1 infra |
| 3 | Kimi K3 · Claude Code | 60% | 12 of 20 | 20 of 40 |
| 4 | Kimi K3 · mini-swe-agent | 60% | 12 of 20 | 20 of 40 |
| 5 | GLM-5.3 · mini-swe-agent | 50% | 9 of 18 | 20 of 40 · 2 infra |
| 6 | GLM-5.3 · Codex | 32% | 6 of 19 | 20 of 40 · 1 infra |
| Ran fewer of these tasks, not ranked | ||||
| Opus 5.5 · Claude Code | no scored trial | 4 of 40 · 4 stopped | ||
VLA policies
| Rank# | Model · harness | Solve rate | Solved | Tasks run |
|---|---|---|---|---|
| 1 | EVO1-LIBERO · VLA | 100% | 40 of 40 | 40 of 40 |
| 2 | GR00T N1.7-LIBERO · VLA | 95% | 38 of 40 | 40 of 40 |
| 3 | VLA-JEPA-LIBERO · VLA | 95% | 38 of 40 | 40 of 40 |
| 4 | pi0.5-LIBERO · VLA | 95% | 38 of 40 | 40 of 40 |
| 5 | pi0.5-LIBERO (LeRobot) · VLA | 92% | 37 of 40 | 40 of 40 |
| 6 | pi0-LIBERO · VLA | 90% | 36 of 40 | 40 of 40 |
| 7 | pi0-FAST-LIBERO (LeRobot) · VLA | 82% | 32 of 39 | 39 of 40 |
| 8 | pi0-LIBERO (LeRobot) · VLA | 75% | 30 of 40 | 40 of 40 |
| 9 | SmolVLA-LIBERO · VLA | 65% | 26 of 40 | 40 of 40 |
| Ran fewer of these tasks, not ranked | ||||
| MolmoAct2-LIBERO · VLA | 100% | 20 of 20 | 20 of 40 | |
Per task
✓ solved ✗ not solved ! infrastructure failure ‖ stopped, not scored · not run